 2
Glorious Model D3 Wireless Review
Testing 8000 Hz Wireless »Sensor and Performance
The Glorious Model D3 Wireless is equipped with the BAMF 3.0 sensor, which is a PixArt PAW3950. According to specifications, the 3950 is capable of up to 30,000 CPI, as well as a maximum tracking speed of 750 IPS, which equals 19.05 m/s. Out of the box, six pre-defined CPI steps are available: 400, 800, 1600, 3200, 6400, and 12,800.All testing was done on the latest firmware (1.4.0). As such, results obtained on earlier firmware versions may differ from those presented hereafter.
CPI Accuracy
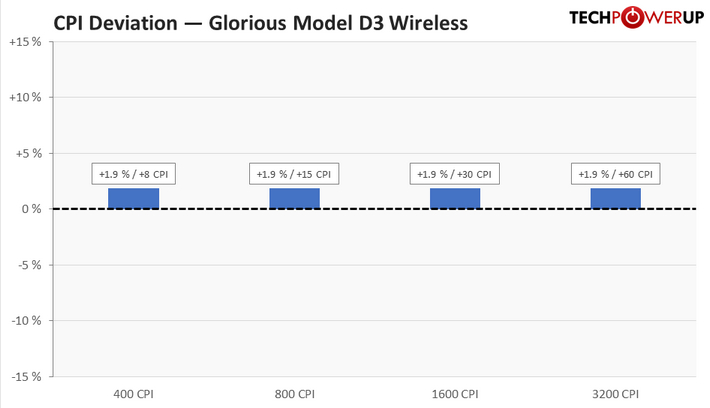
I've restricted my testing to the four most common CPI steps, which are 400, 800, 1600, and 3200. As you can see, deviation is consistently positive and low, which is a very good result overall. In order to account for the measured deviation, adjusted steps of 400, 800, 1550, and 3150 CPI have been used for testing.
Motion Delay
Wired testing
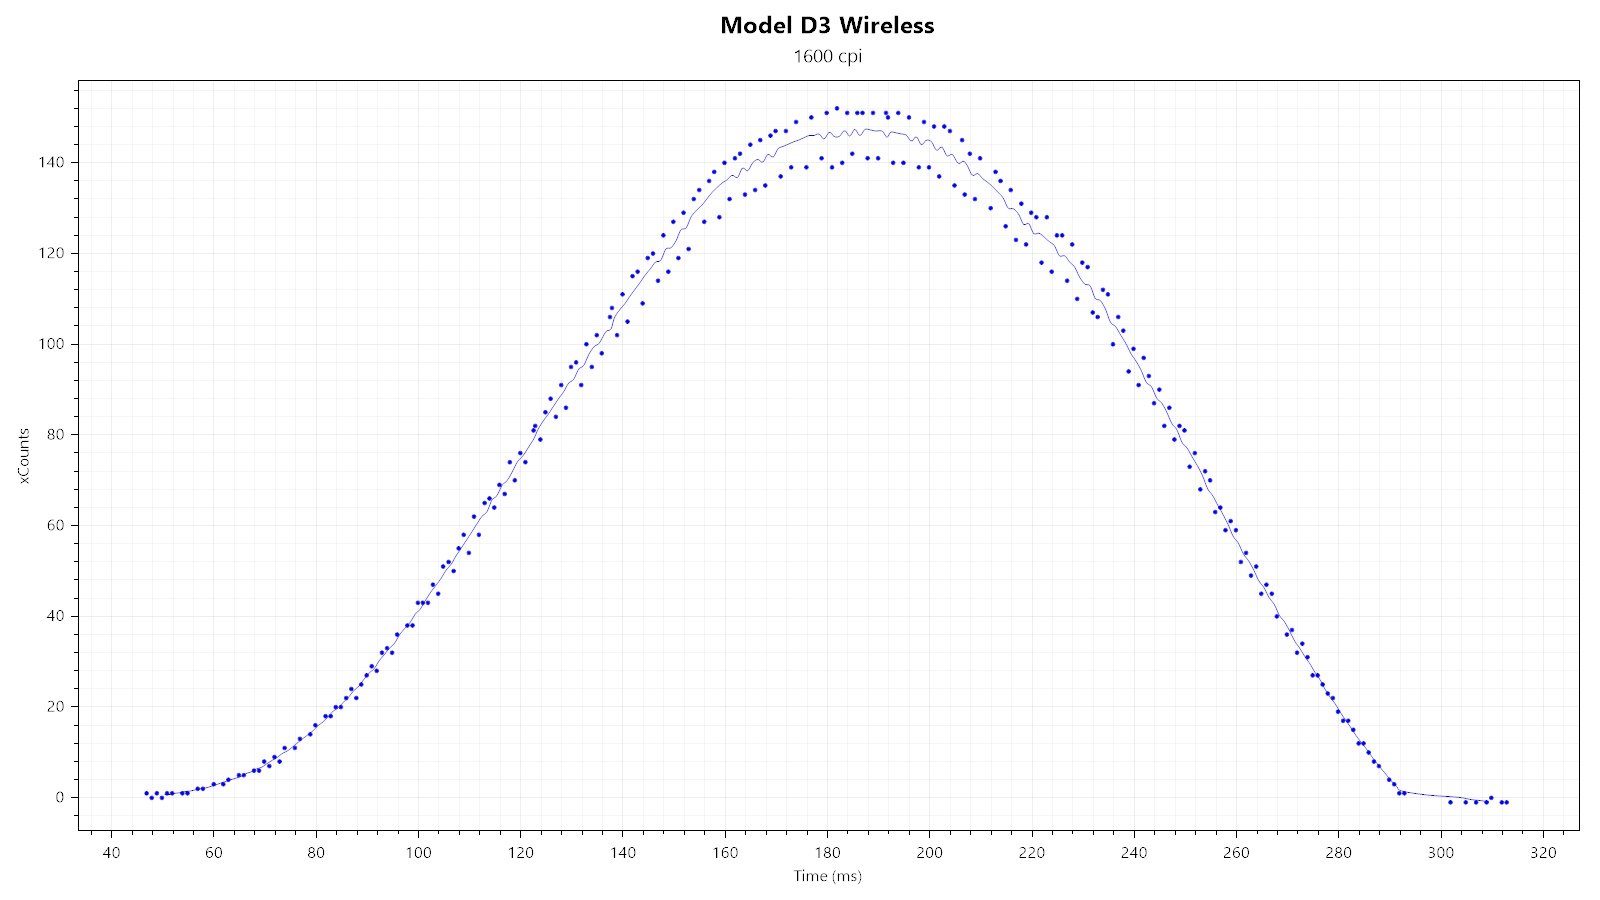
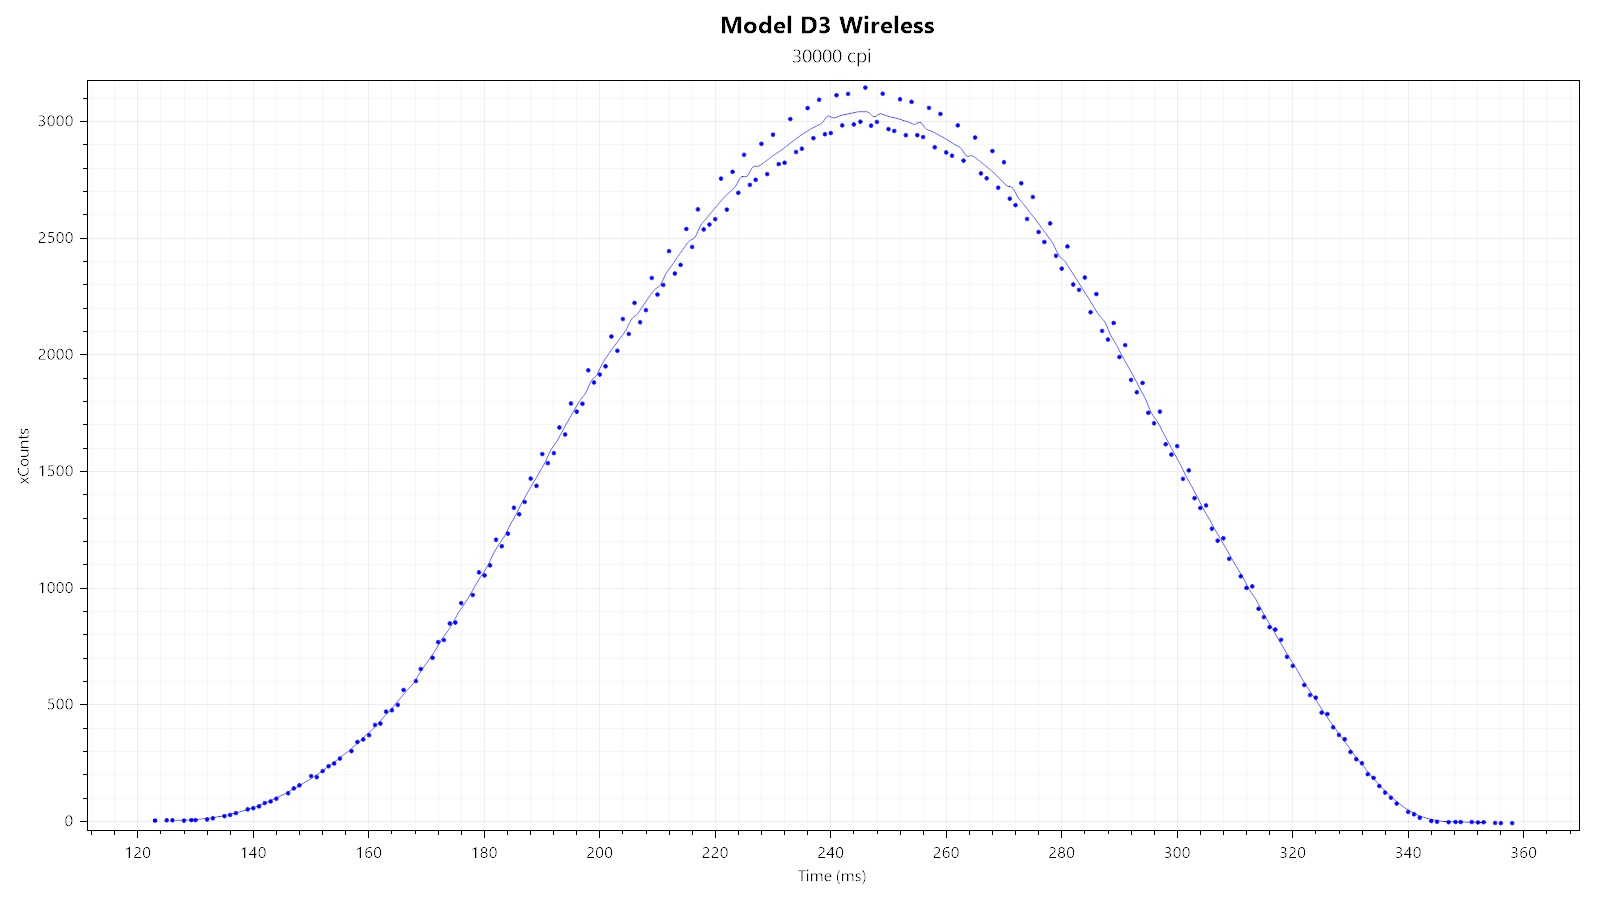
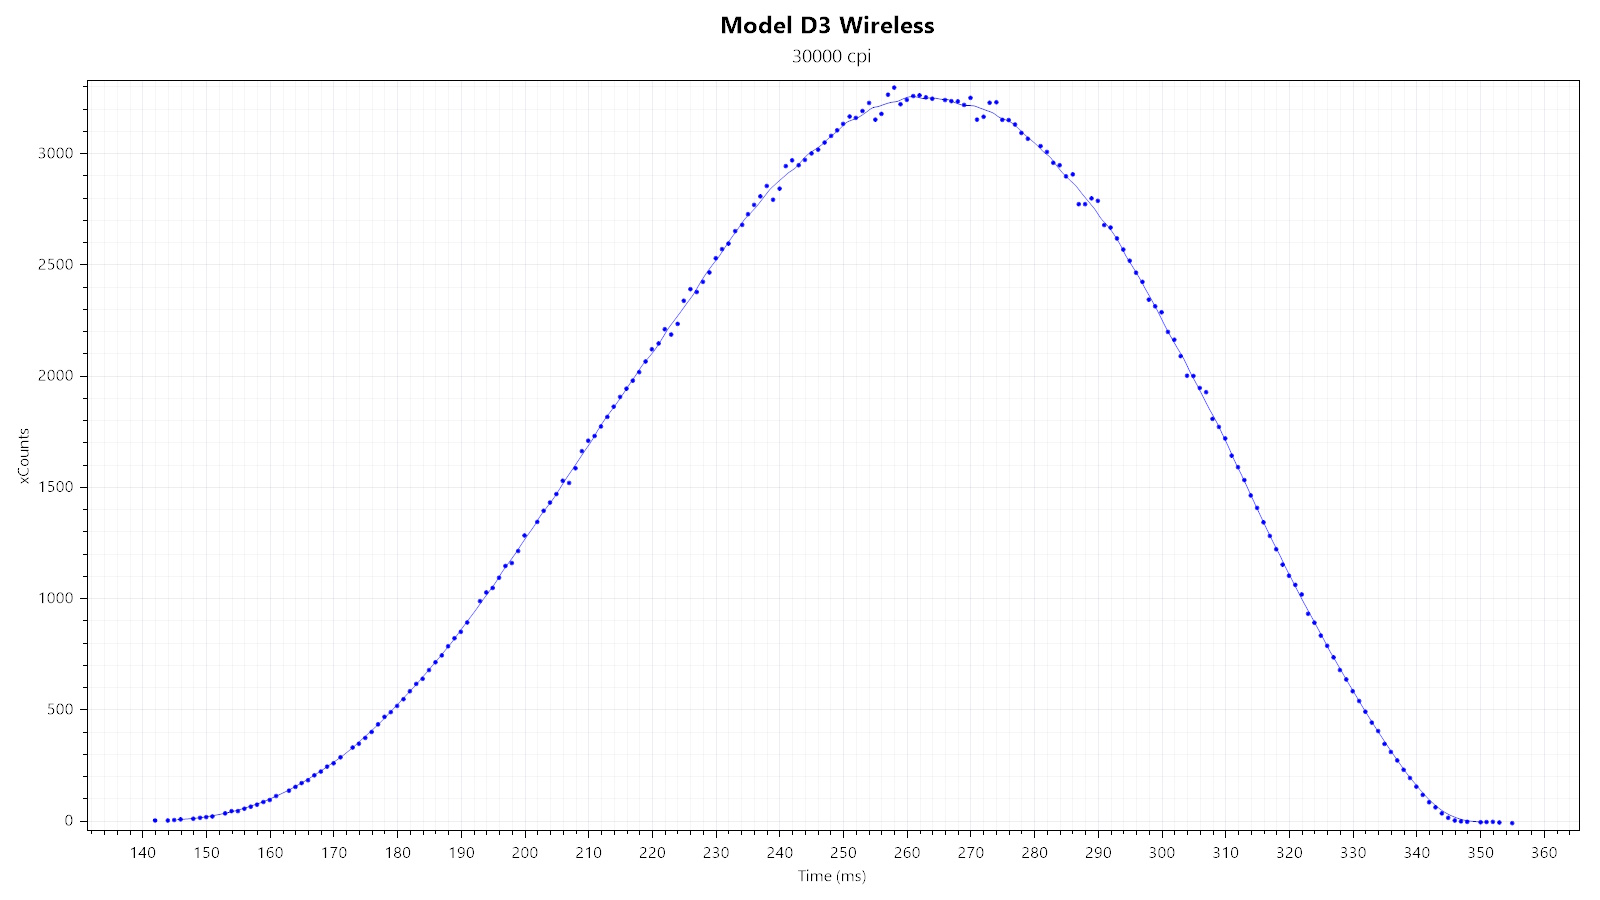
First, I'm looking at two xCounts plots—generated at 1600 and 30,000 CPI—to quickly gauge whether there is any smoothing, which would be indicated by any visible "kinks." Neither plot shows any kinks, strongly suggesting there not being any smoothing across the entire CPI range. The Model D3 Wireless defaults to the corded sensor run mode.
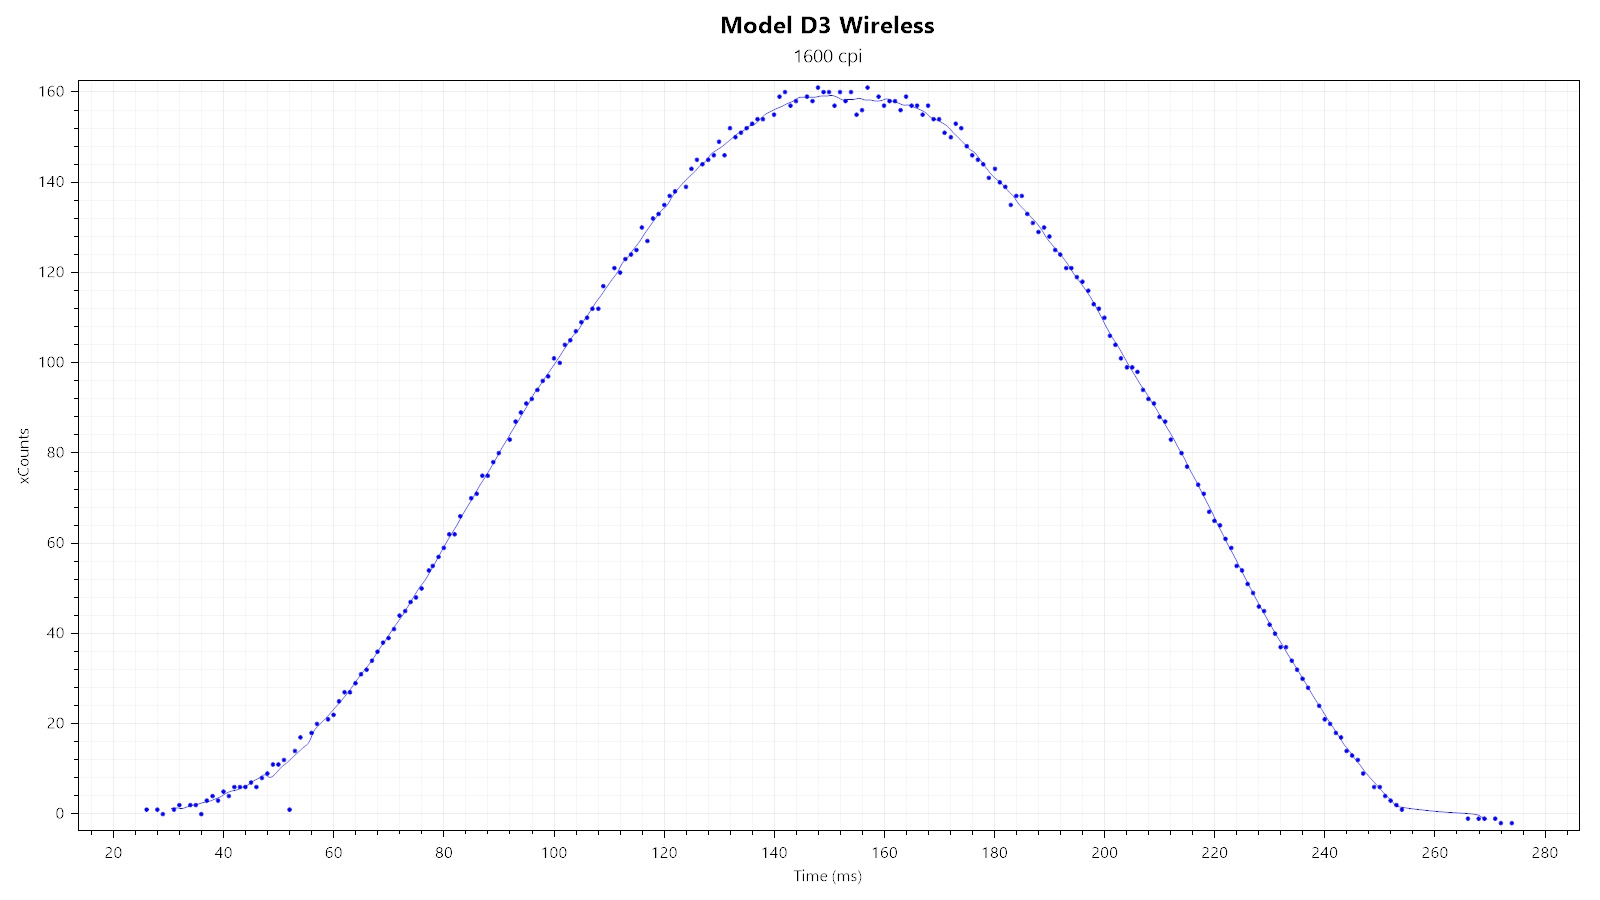
The Model D3 Wireless also allows enabling MotionSync, which effectively synchronizes SPI reads with USB polls, resulting in very low SPI timing jitter as seen above.
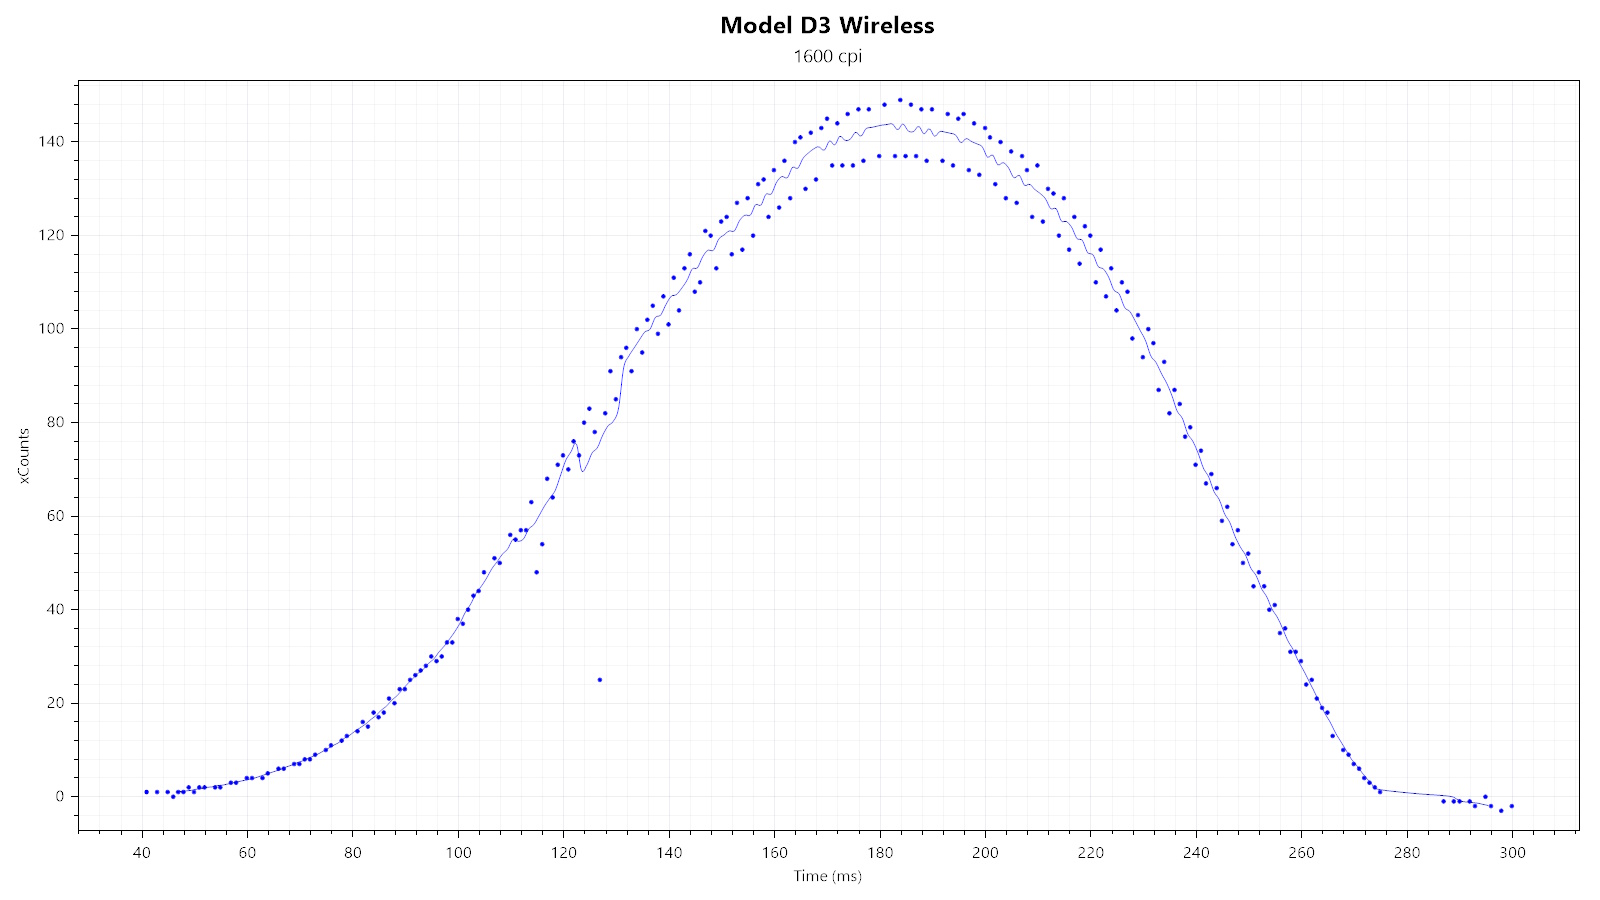
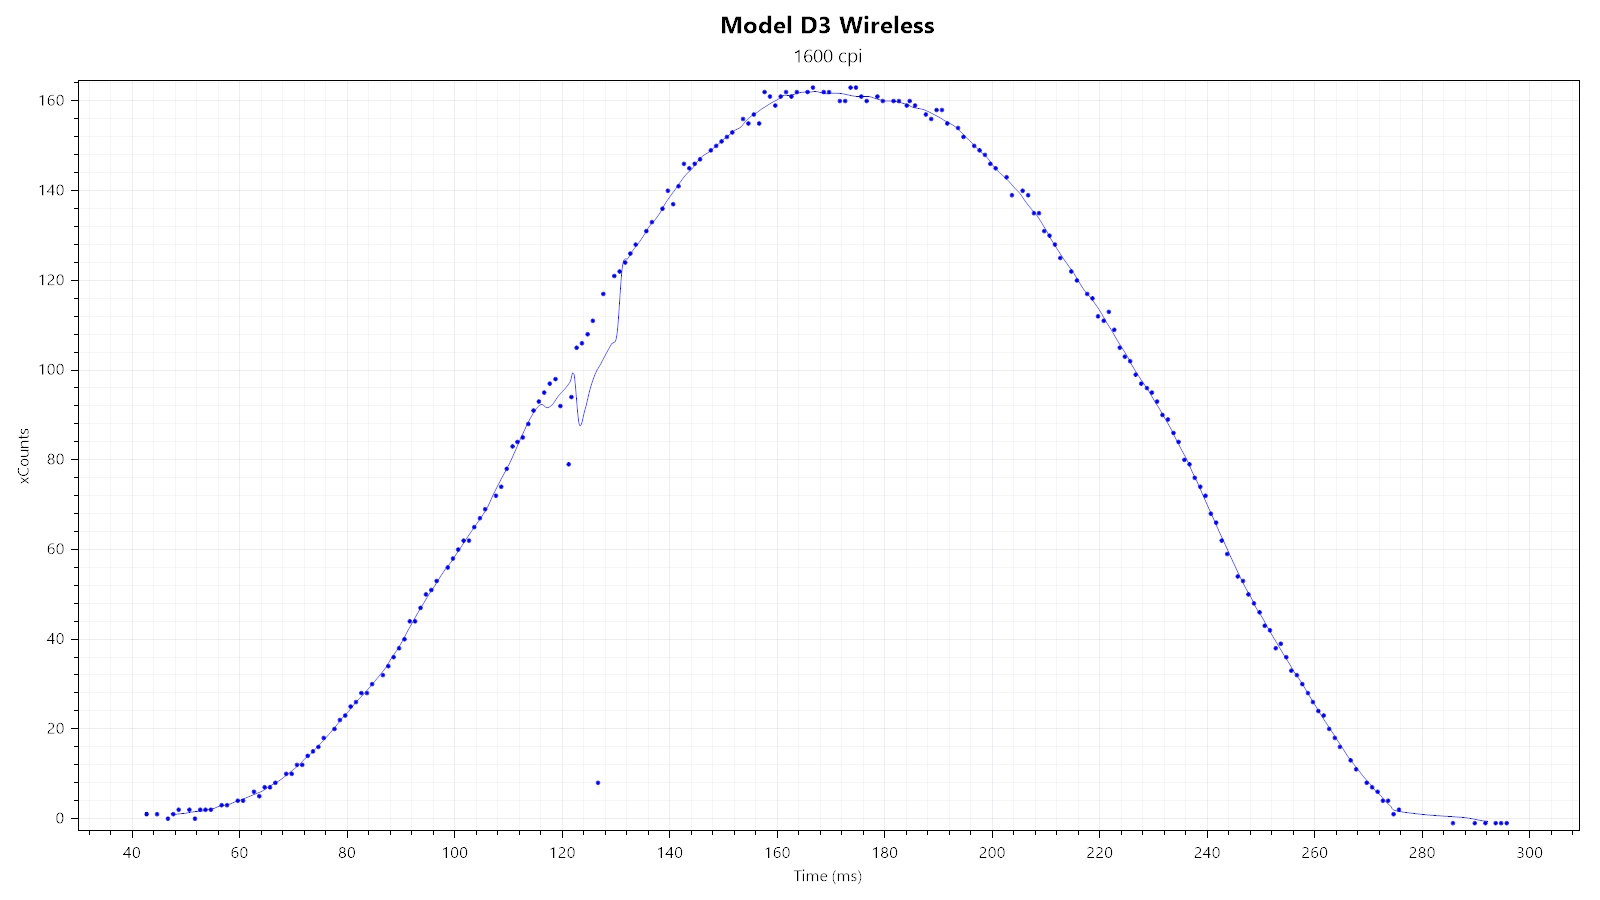
Regardless of MotionSync being enabled or disabled, outliers regularly show up, though they aren't polling-related.
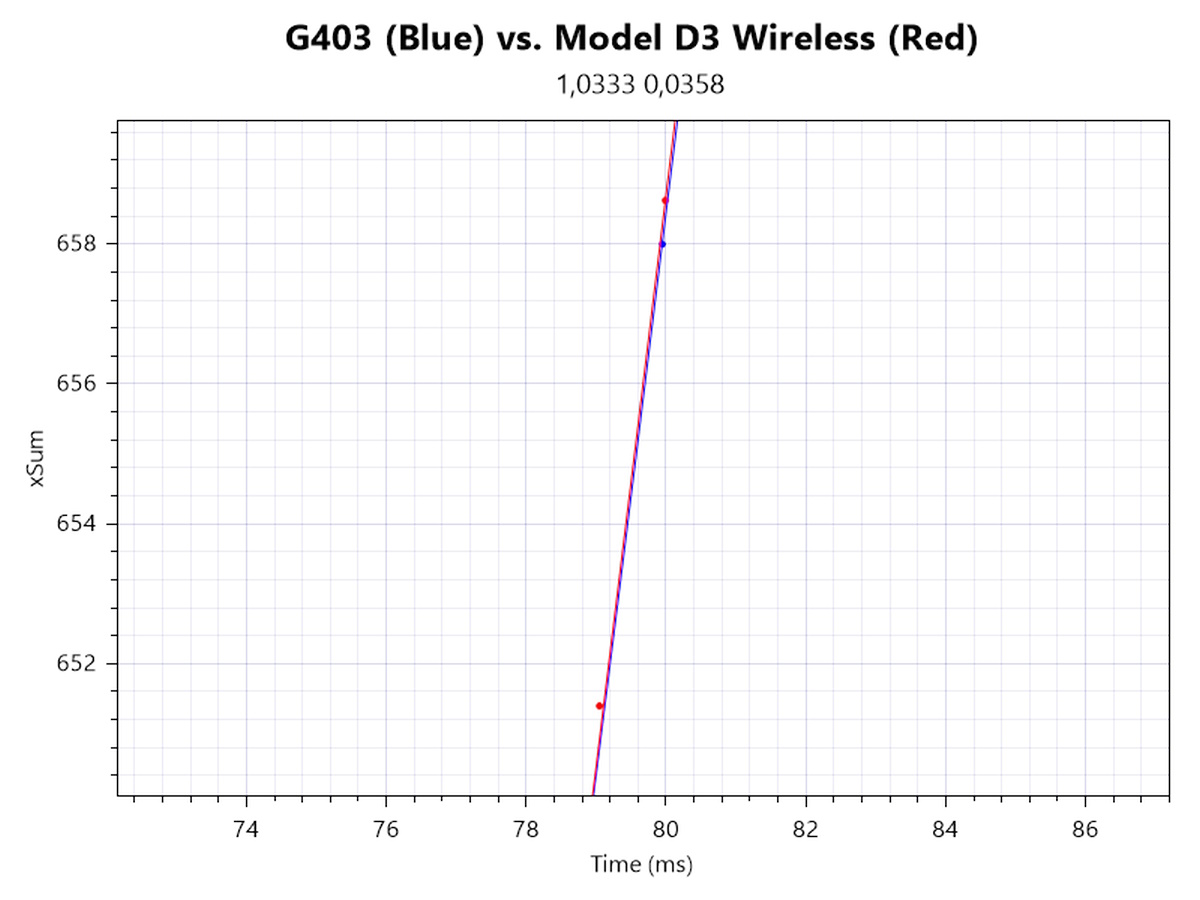
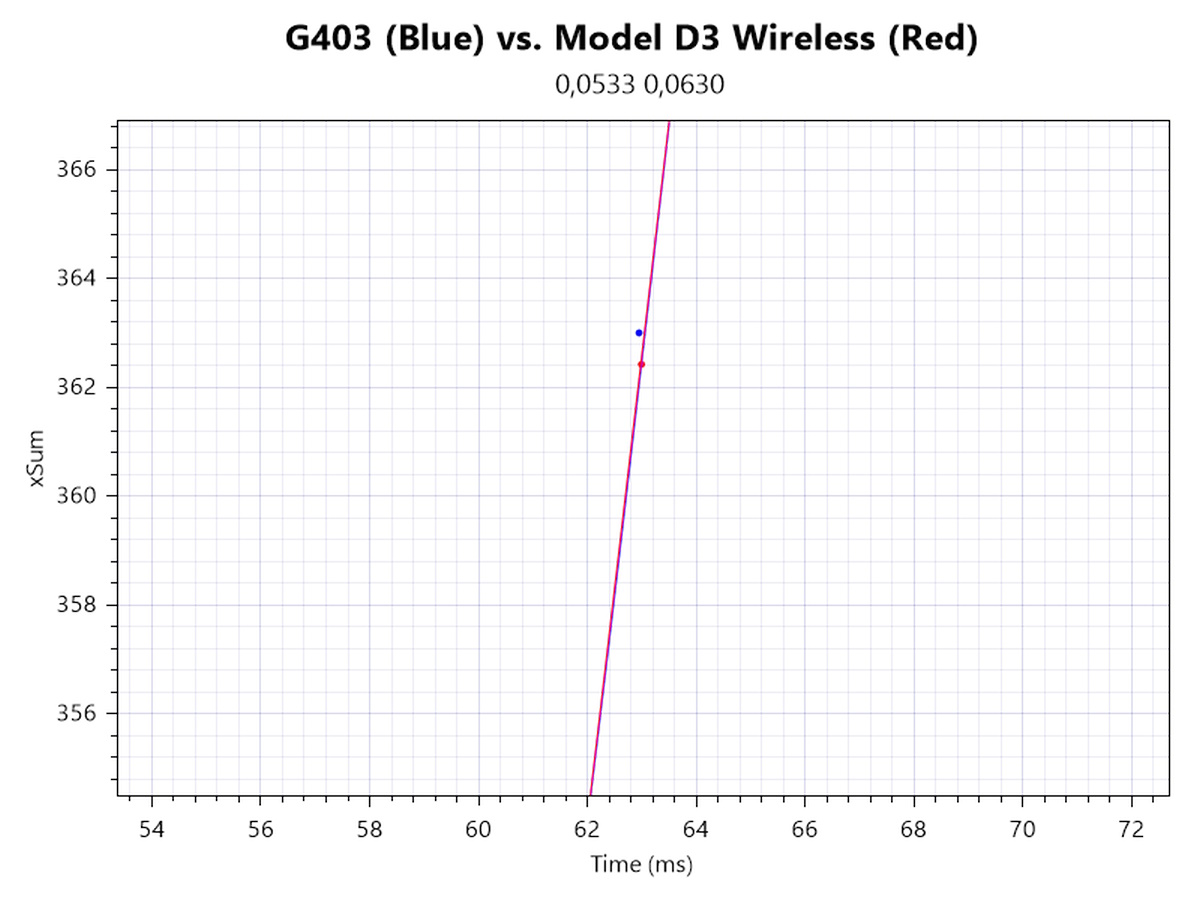
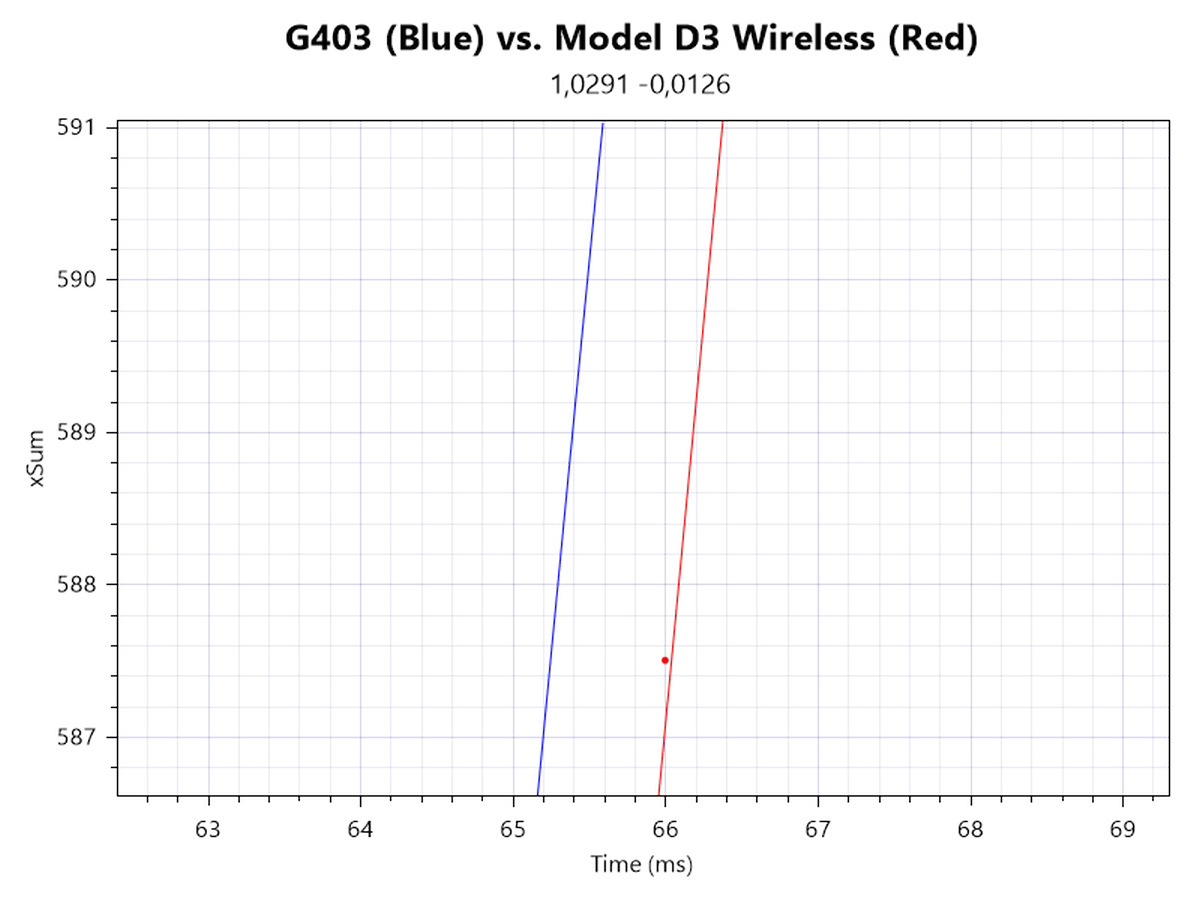
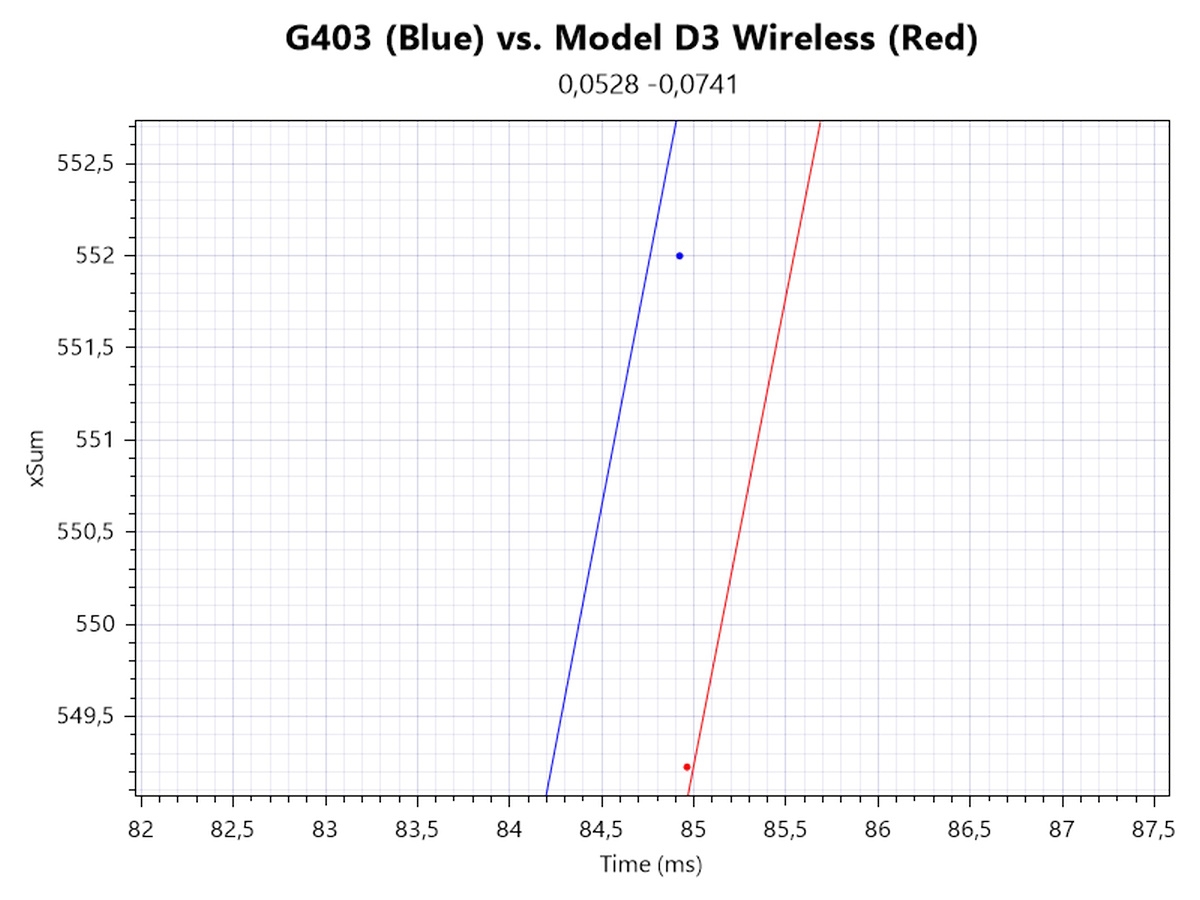
In order to determine motion delay, I'm looking at xSum plots generated at 1600 and 30,000 CPI, both without (first row) and with (second row) MotionSync. The line further to the left denotes the sensor with less motion delay. Without MotionSync, there is no motion delay differential at both 1600 and 30,000 CPI. With MotionSync, a motion delay differential of close to 1 ms is added.
Wireless testing
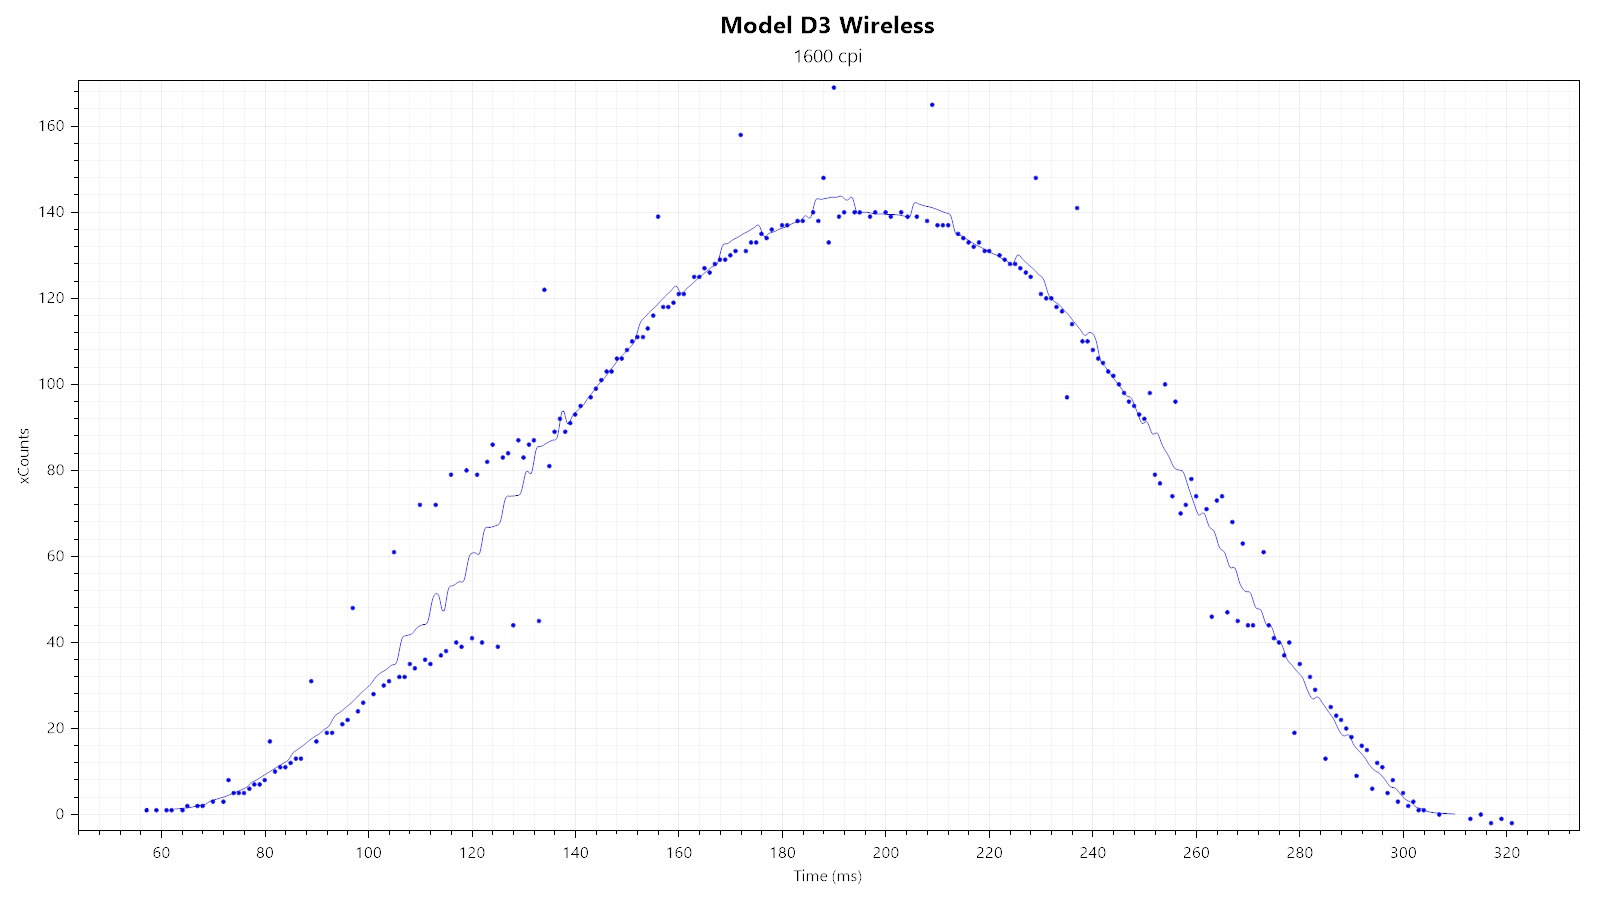
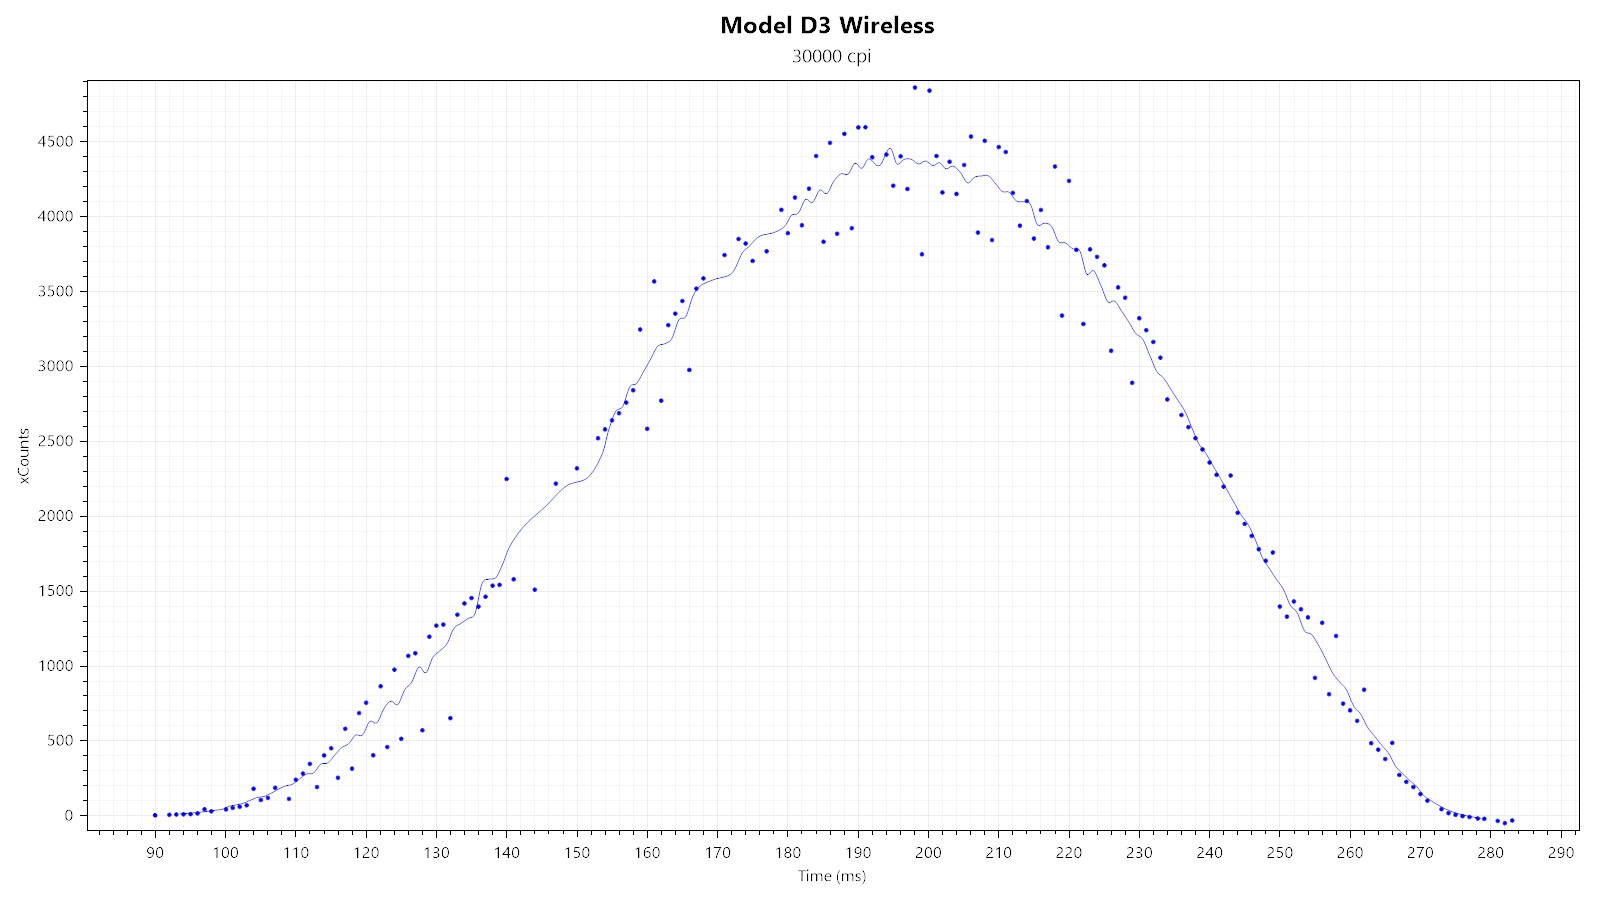
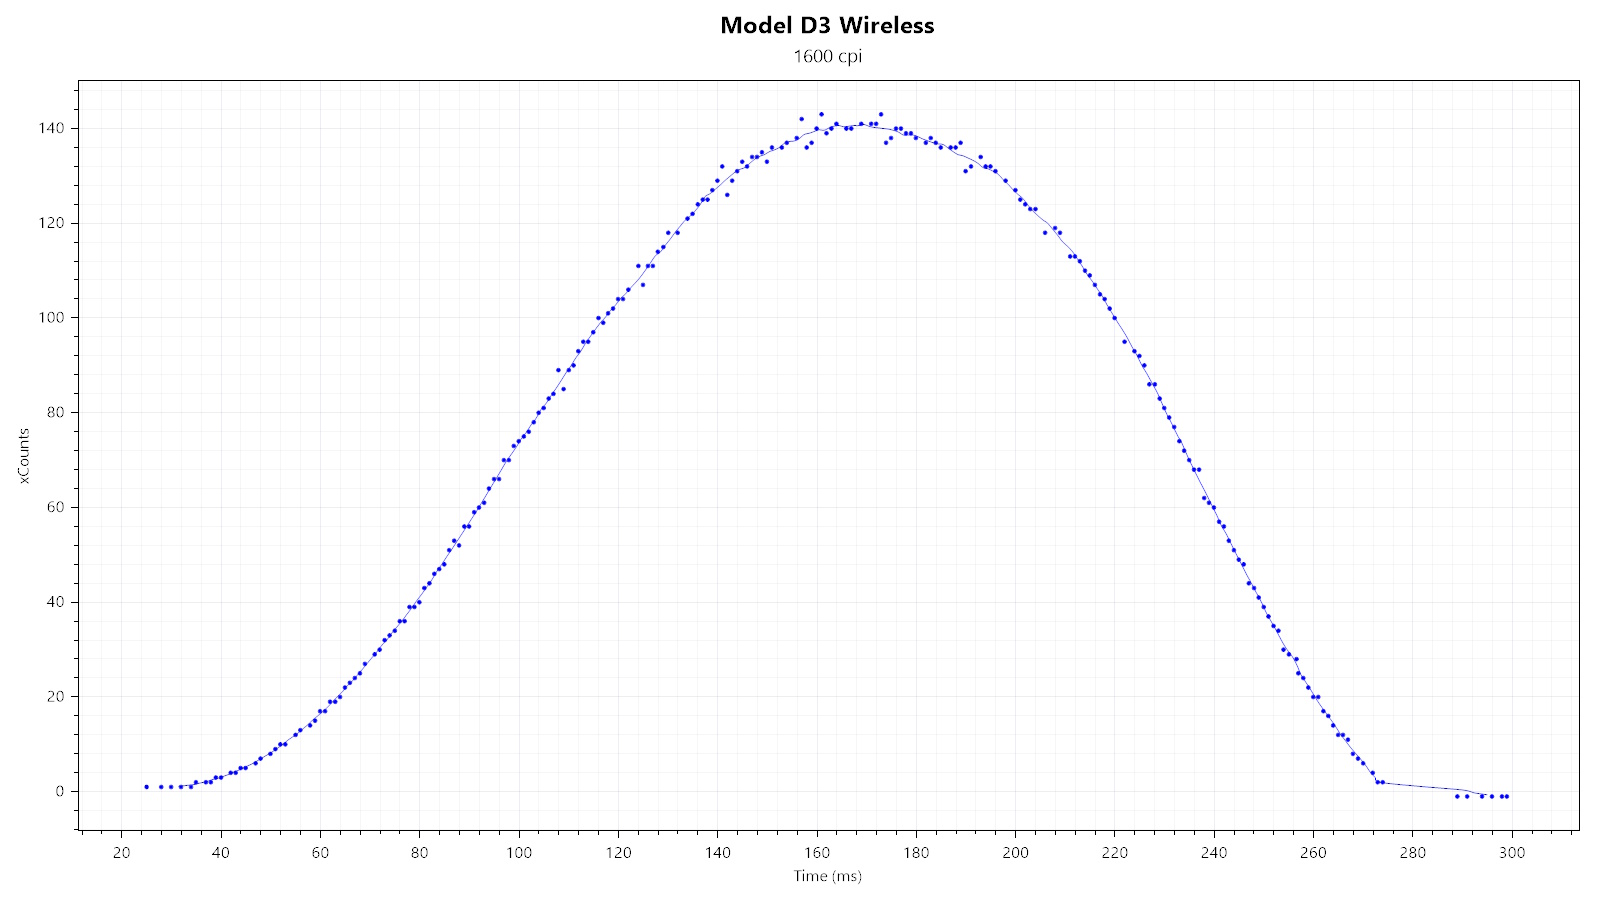
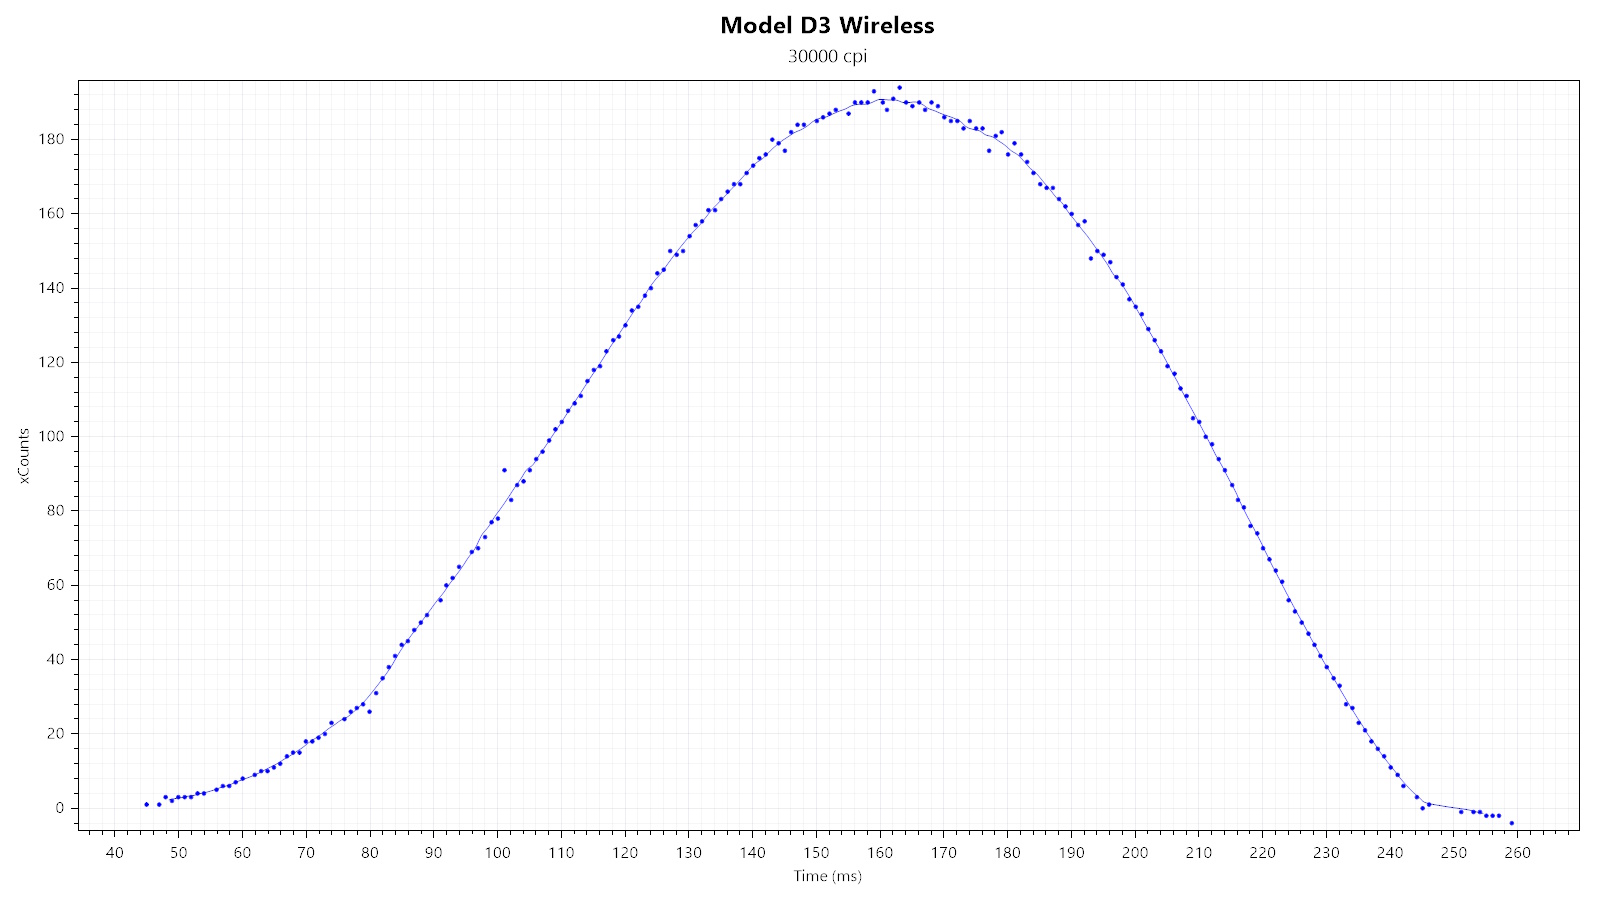
Unlike wired mode, which defaults to the corded sensor run mode, wireless mode defaults to the LP (low power) sensor run mode, resulting in accordingly higher SPI timing jitter.
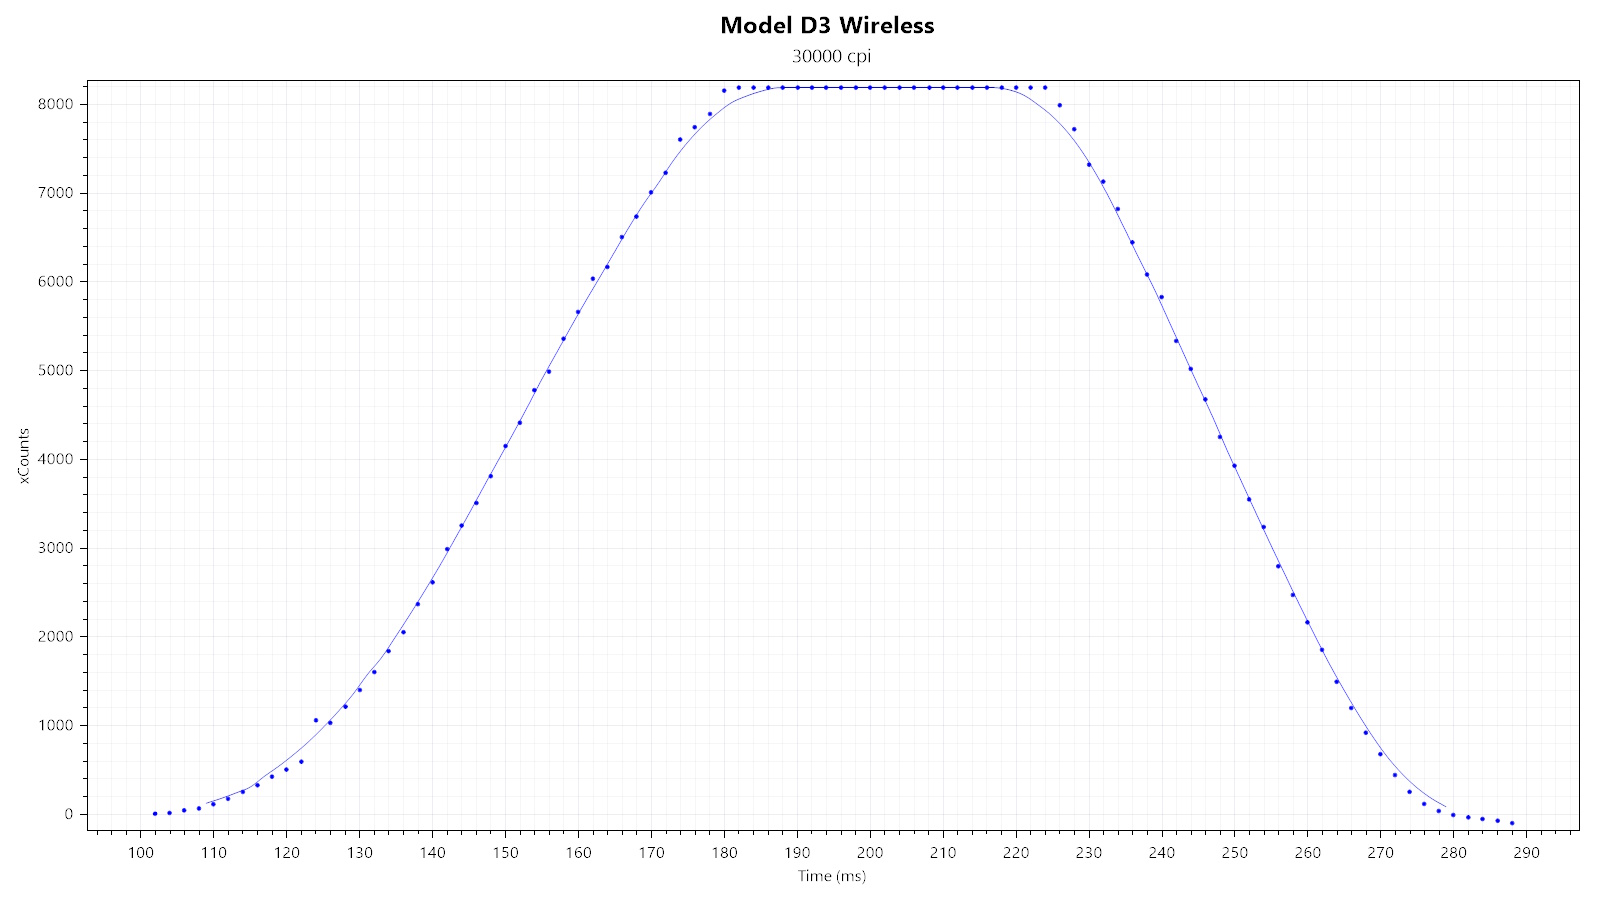
For the record, counts are constrained to 14-bit, which is why a report may not contain more than ±8191 counts. Unless 500 Hz or lower are used (as is the case in the plot above), this won't have an effect in practice, however.
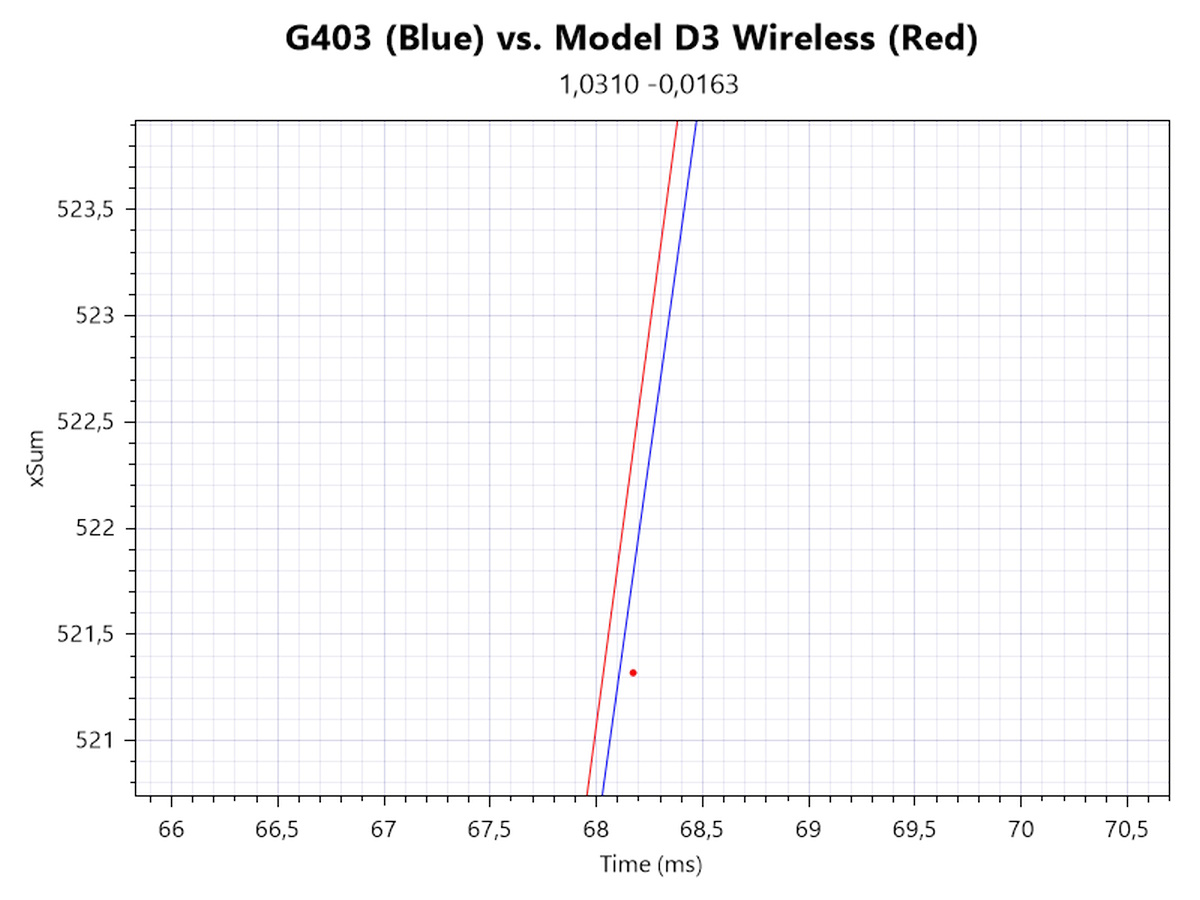
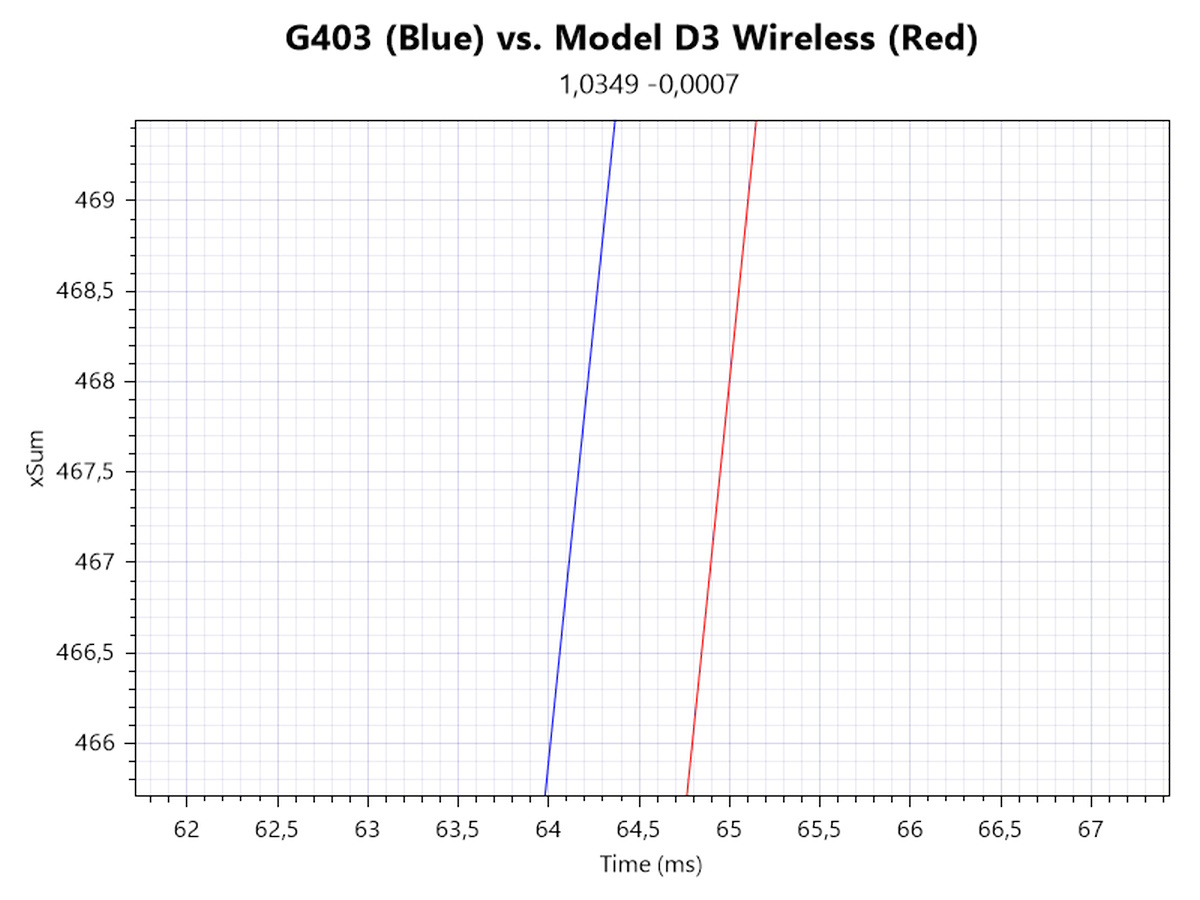
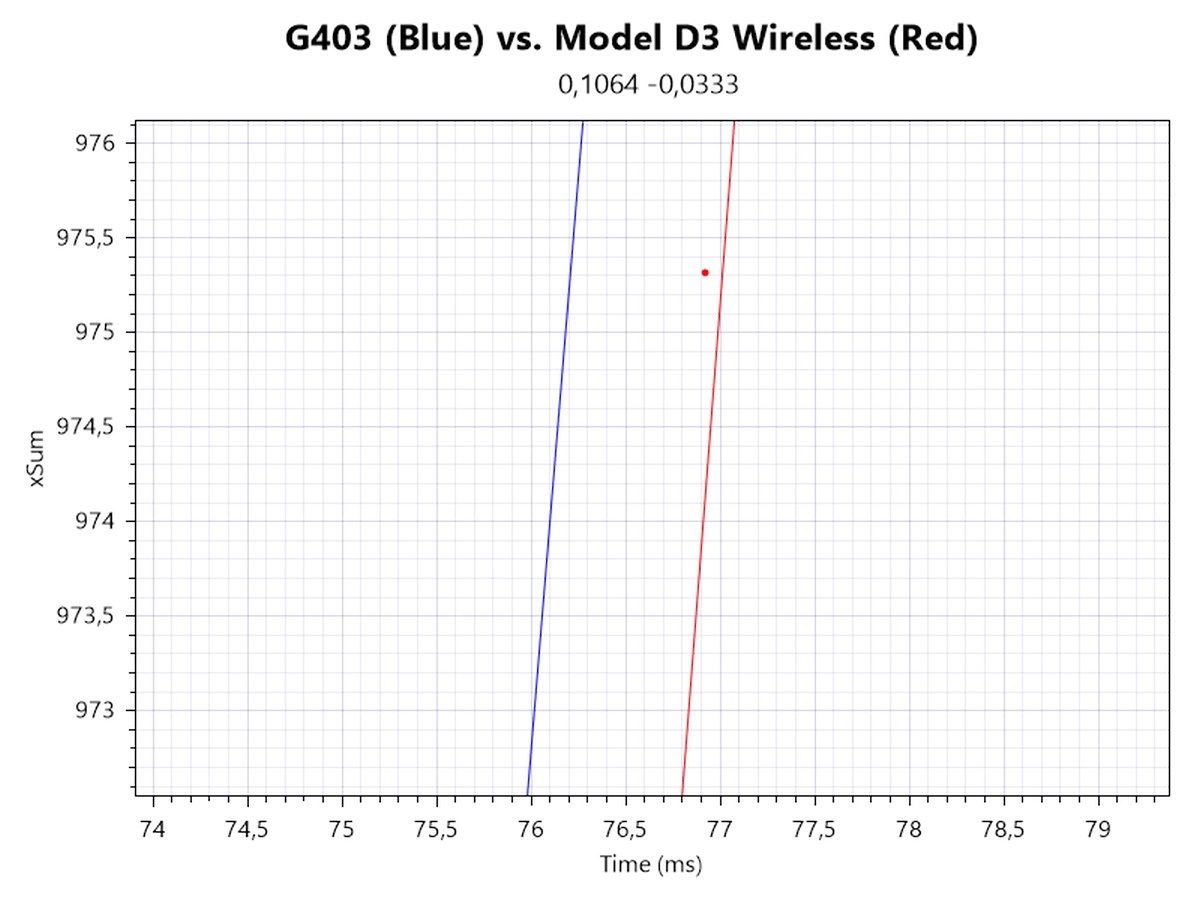
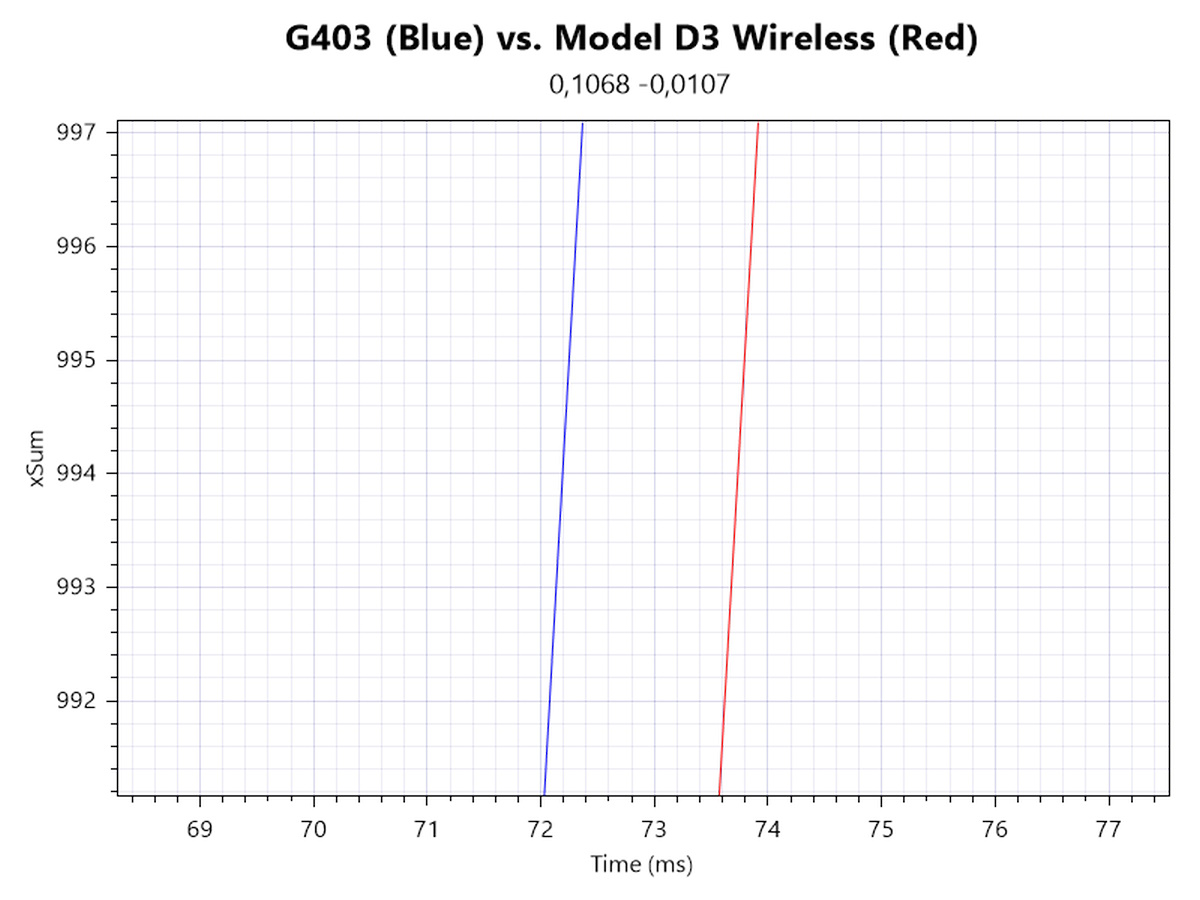
1600 as well as 30,000 CPI both without (first row) and with (second row) MotionSync are tested. At 1600 CPI without MotionSync, there is no motion delay differential, whereas 30,000 CPI with MotionSync shows a motion delay differential of close to 1 ms. With MotionSync, a motion delay differential of close to 1 ms is added at both 1600 and 30,000 CPI.
Speed-related Accuracy Variance (SRAV)
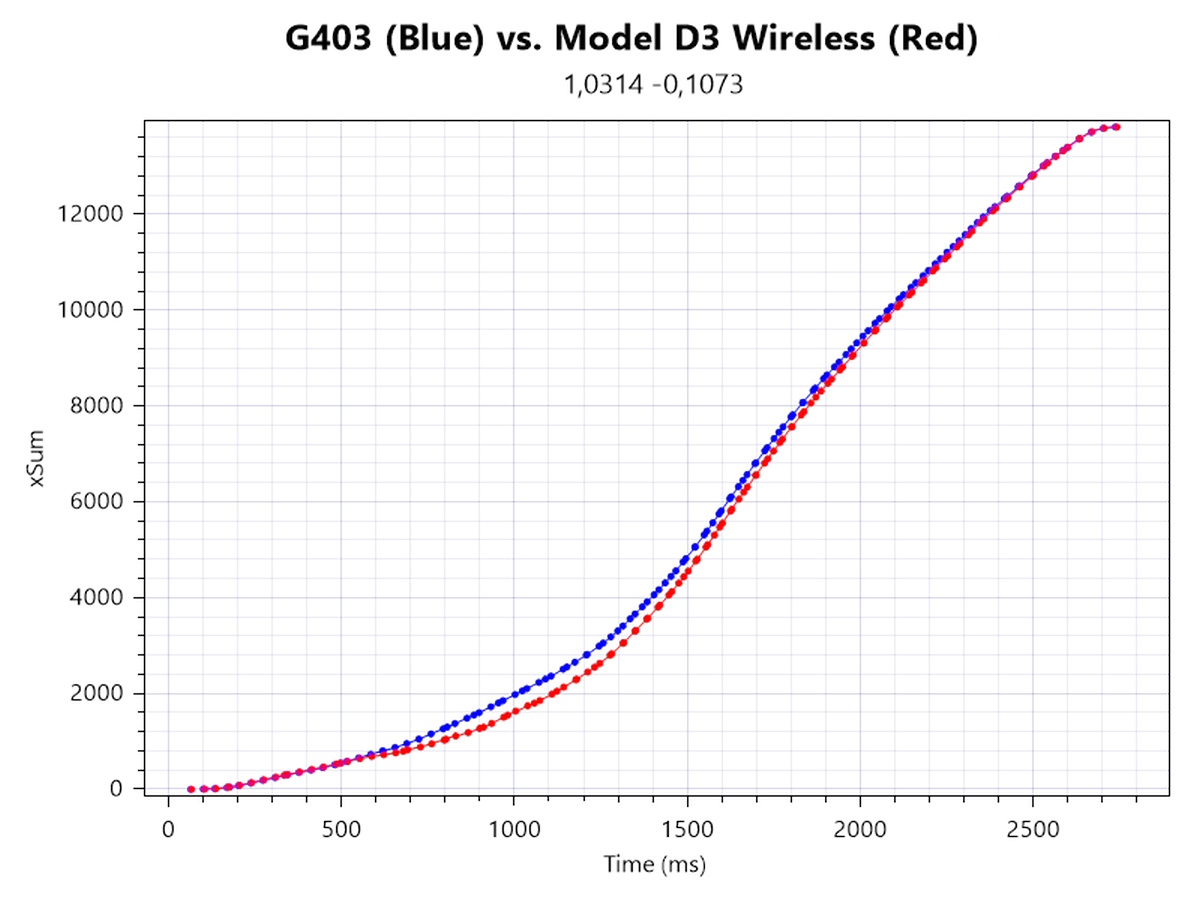
As you can see from the plot, a certain degree of displacement between the two cursor paths can be observed, suggesting elevated SRAV. Please note that this only occurs in wireless operation.
Perfect Control Speed
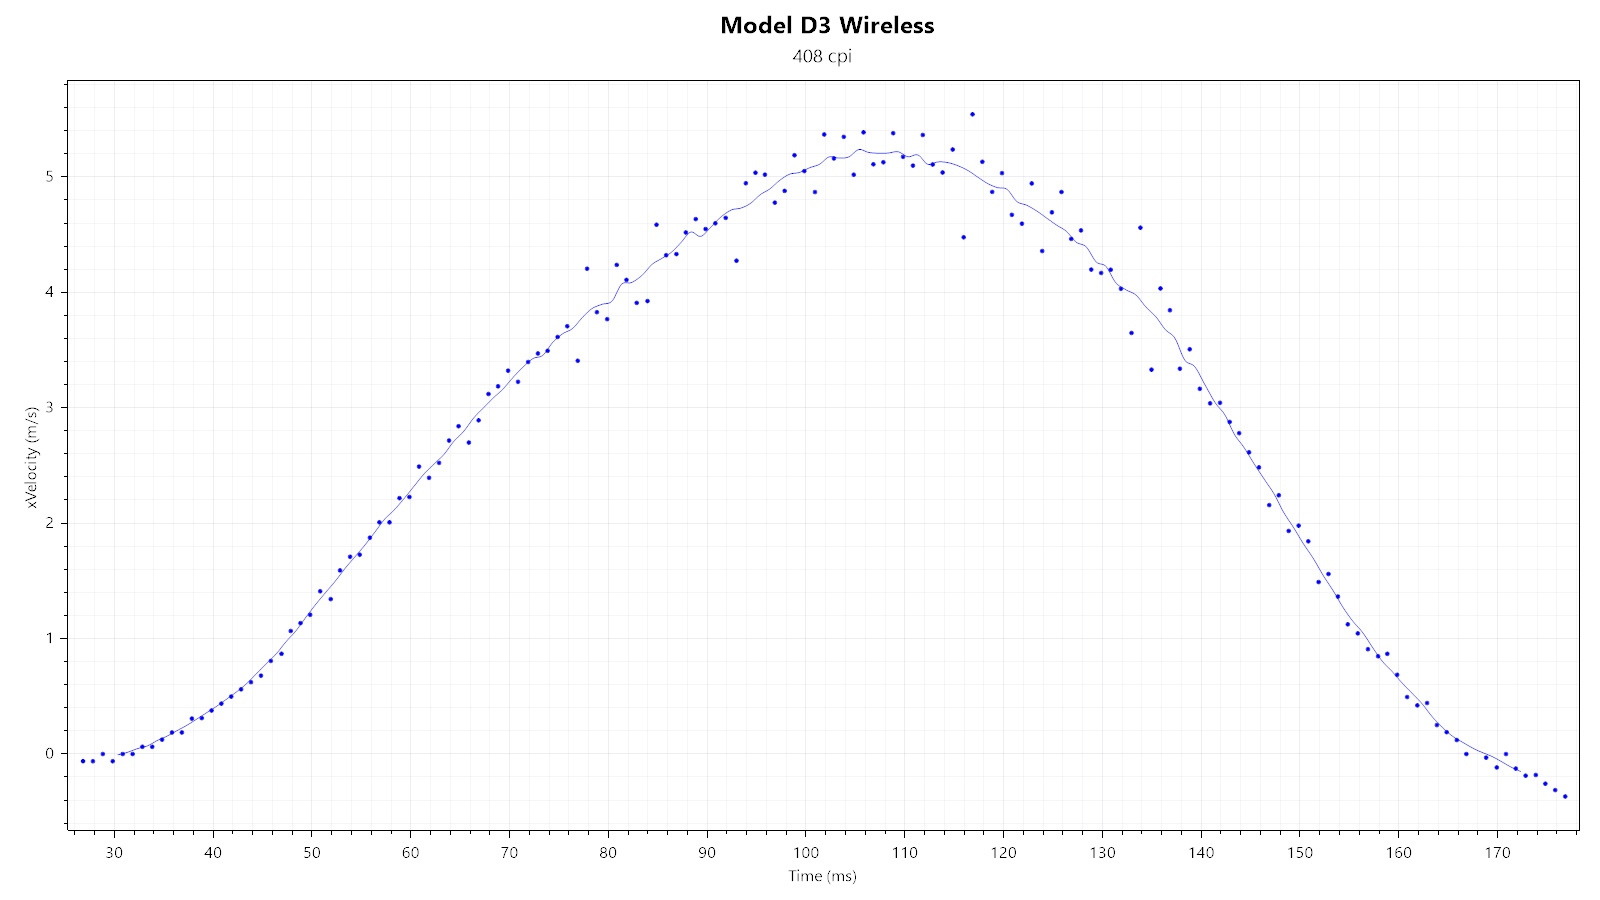
I've only managed to hit a measly 5 m/s, which is within the proclaimed PCS range and causes no observable sensor malfunction. For the record, counts are constrained to 14-bit, which is why a report may not contain more than ±8191 counts. Unless 500 Hz or lower are used, this won't have an effect in practice, however.
Polling Rate Stability
Wired testing
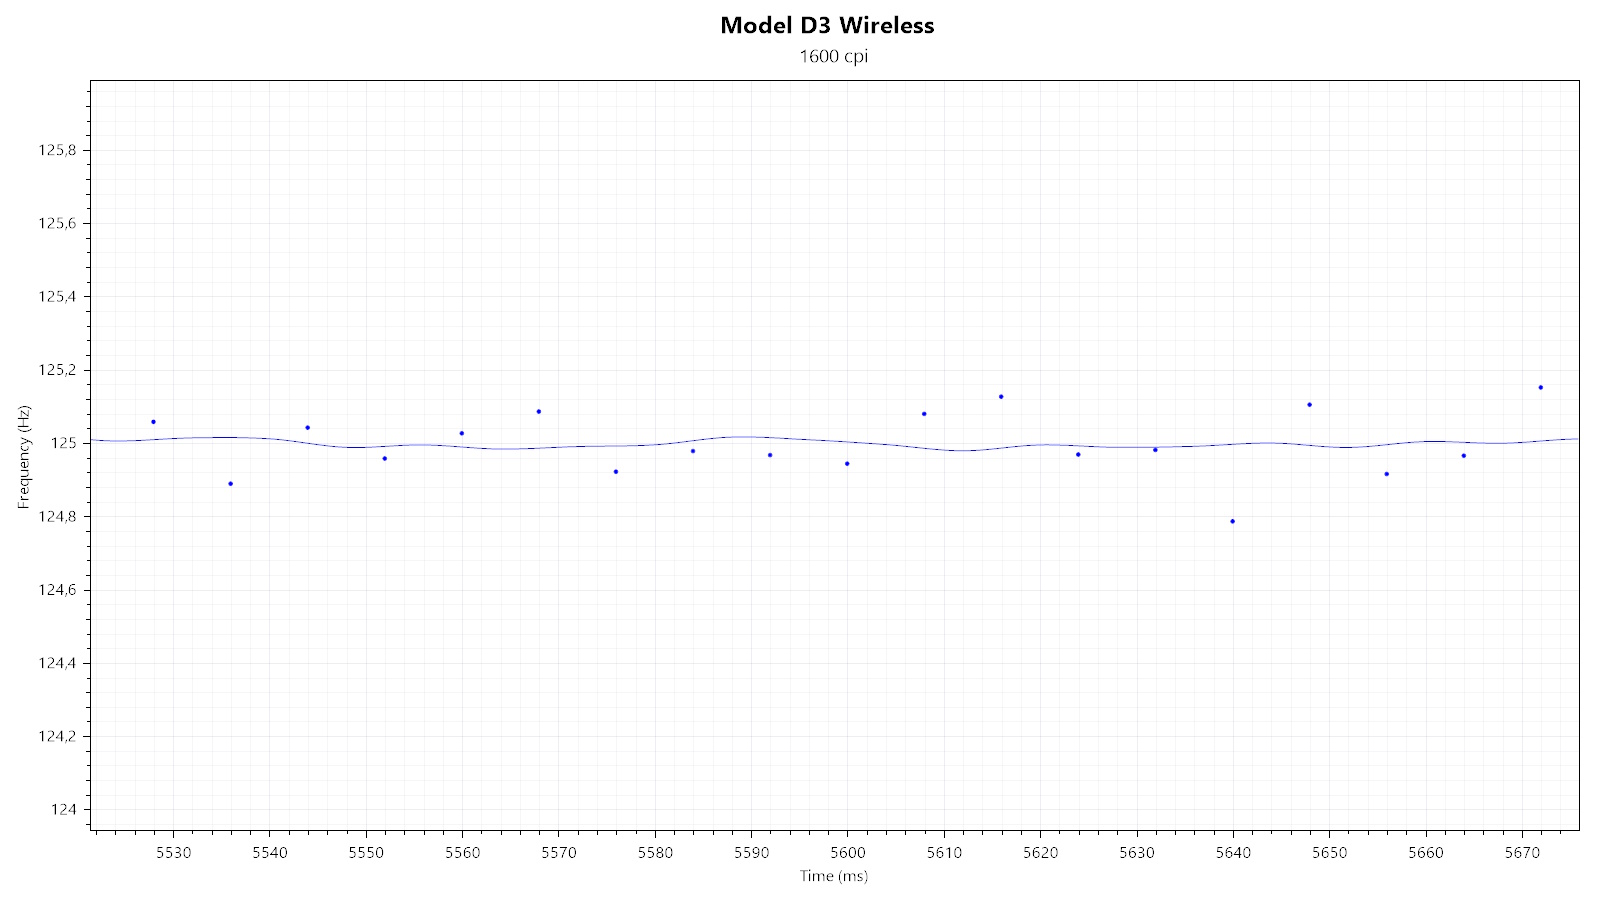
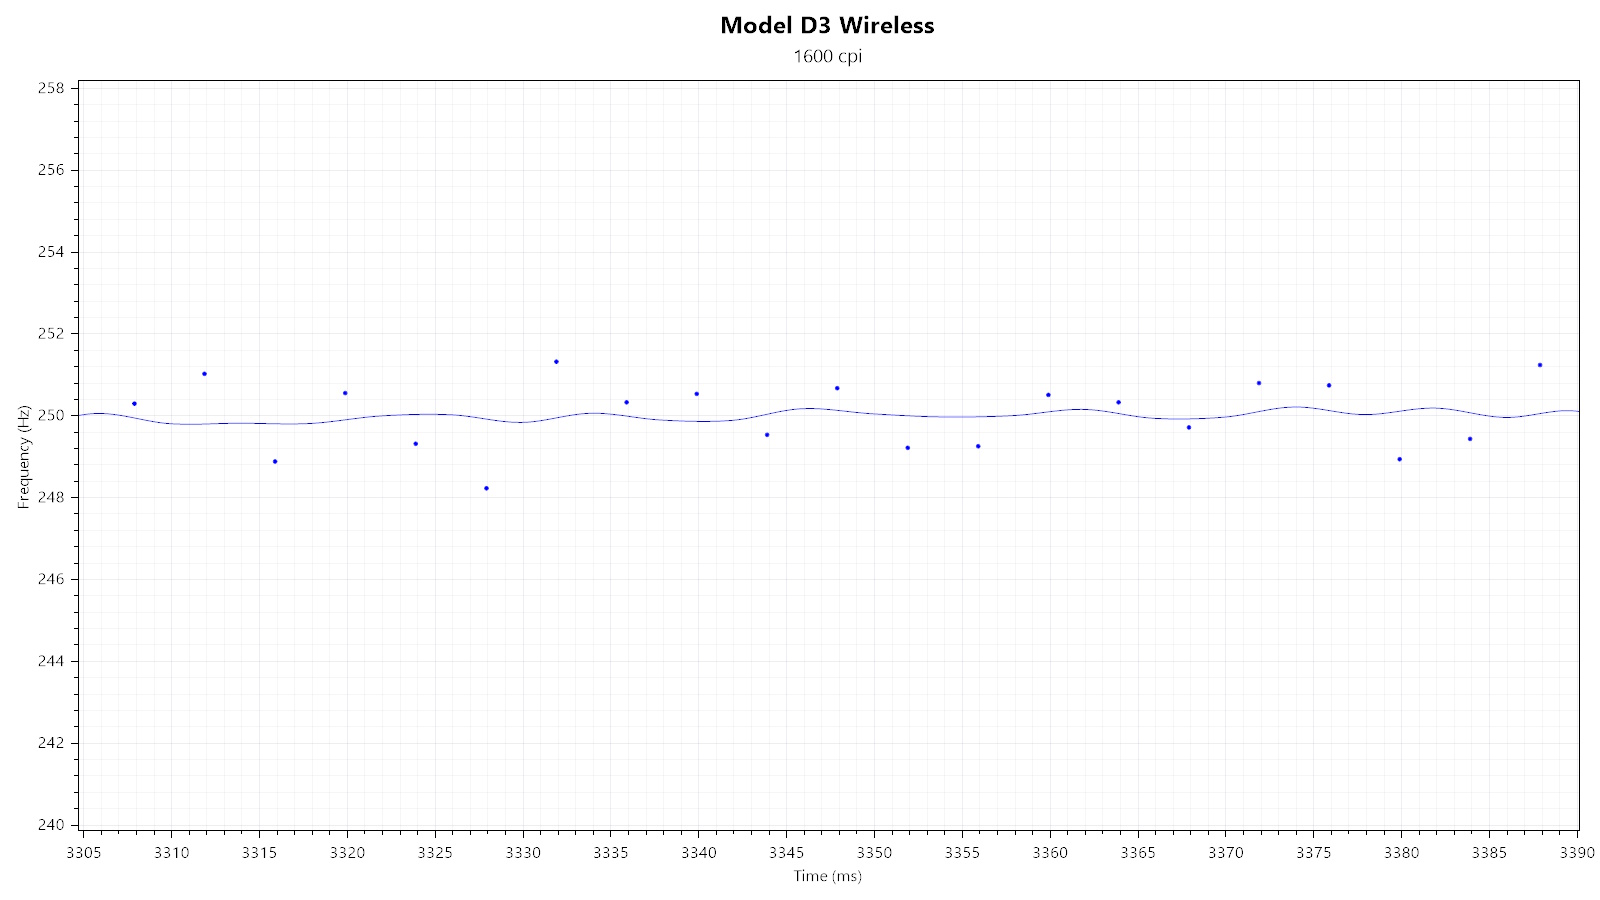
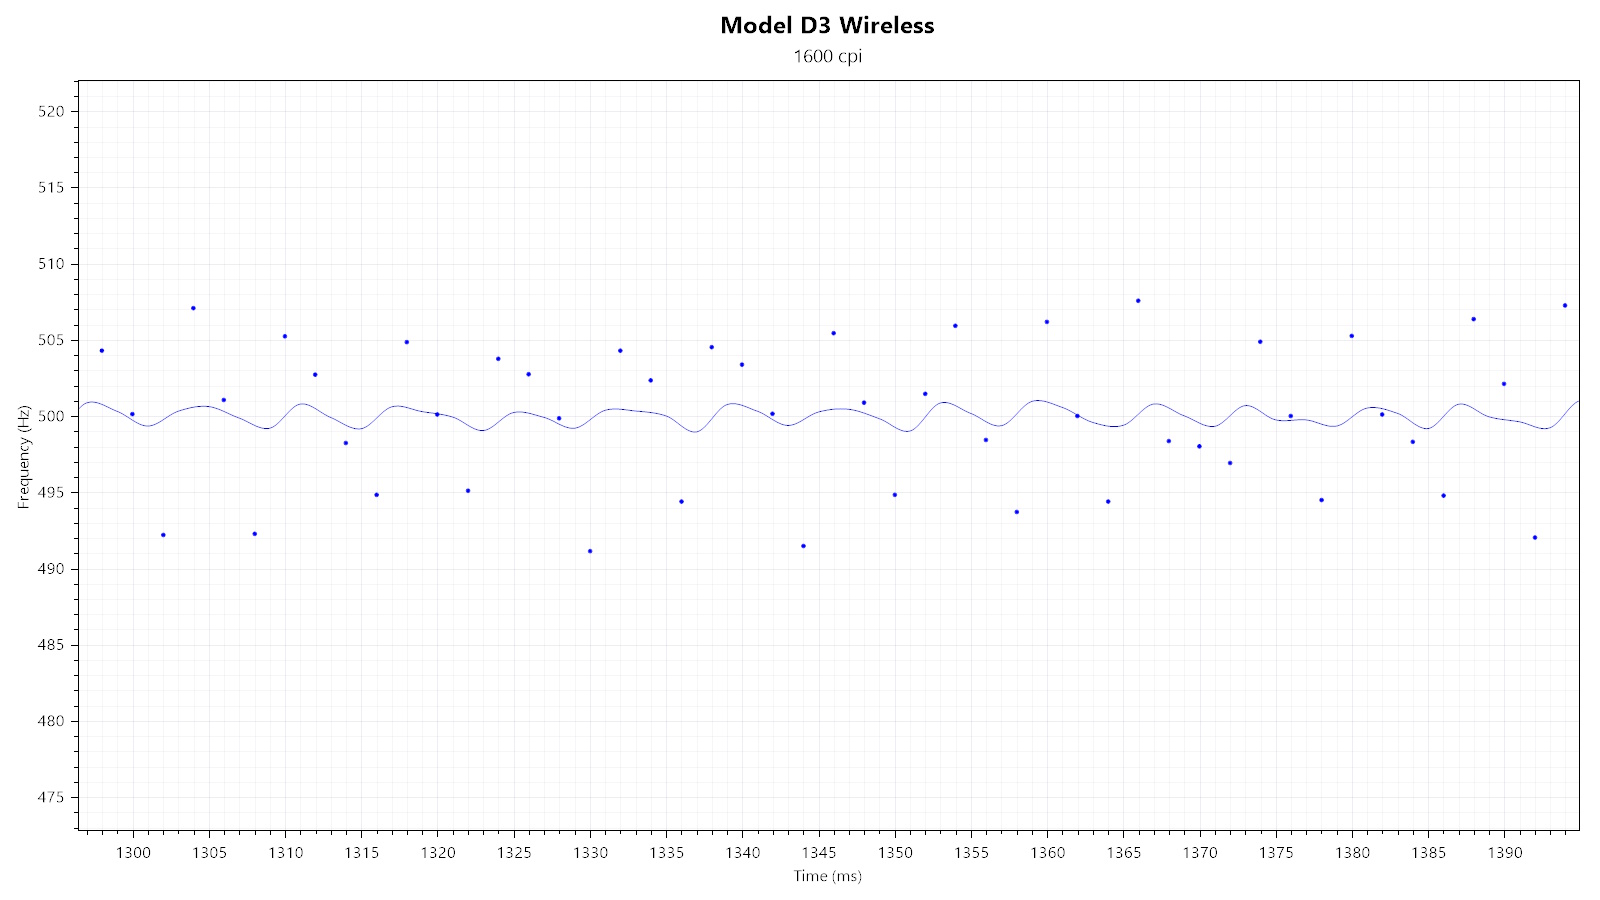
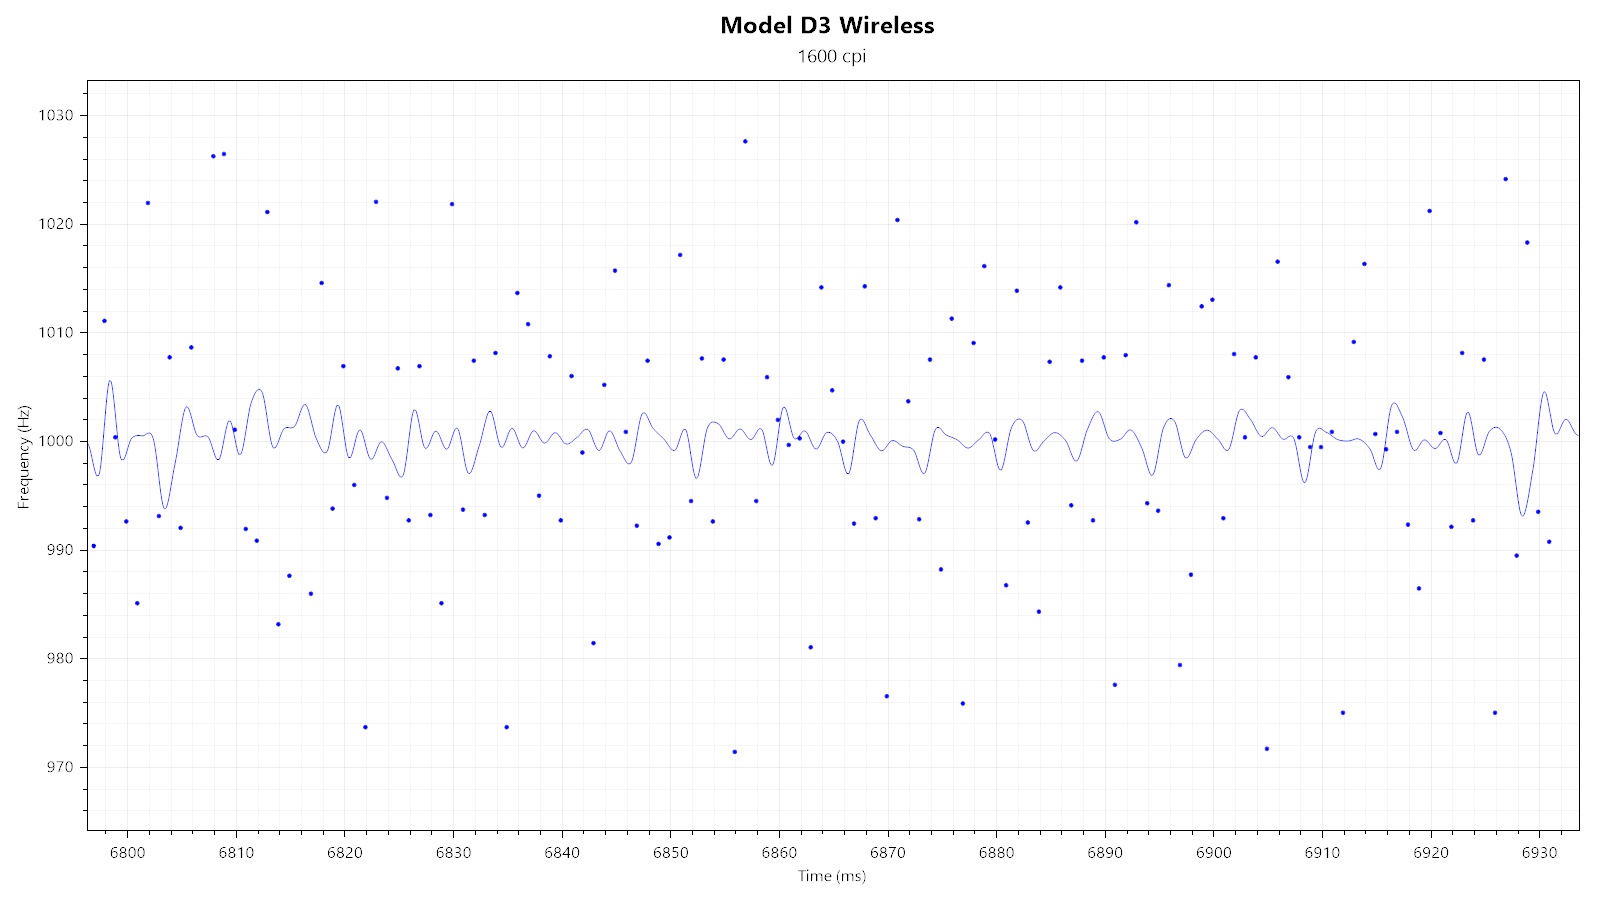
All the available polling rates (125, 250, 500, or 1000 Hz) are fully stable.
Wireless testing
For wired mice, polling rate stability merely concerns the wired connection between the mouse (SPI communication) and USB. For wireless mice, another device that needs to be kept in sync between the first two is added to the mix: the wireless dongle/wireless receiver. I'm unable to measure all stages of the entire end-to-end signal chain individually, so testing polling-rate stability at the endpoint (the USB) has to suffice here.
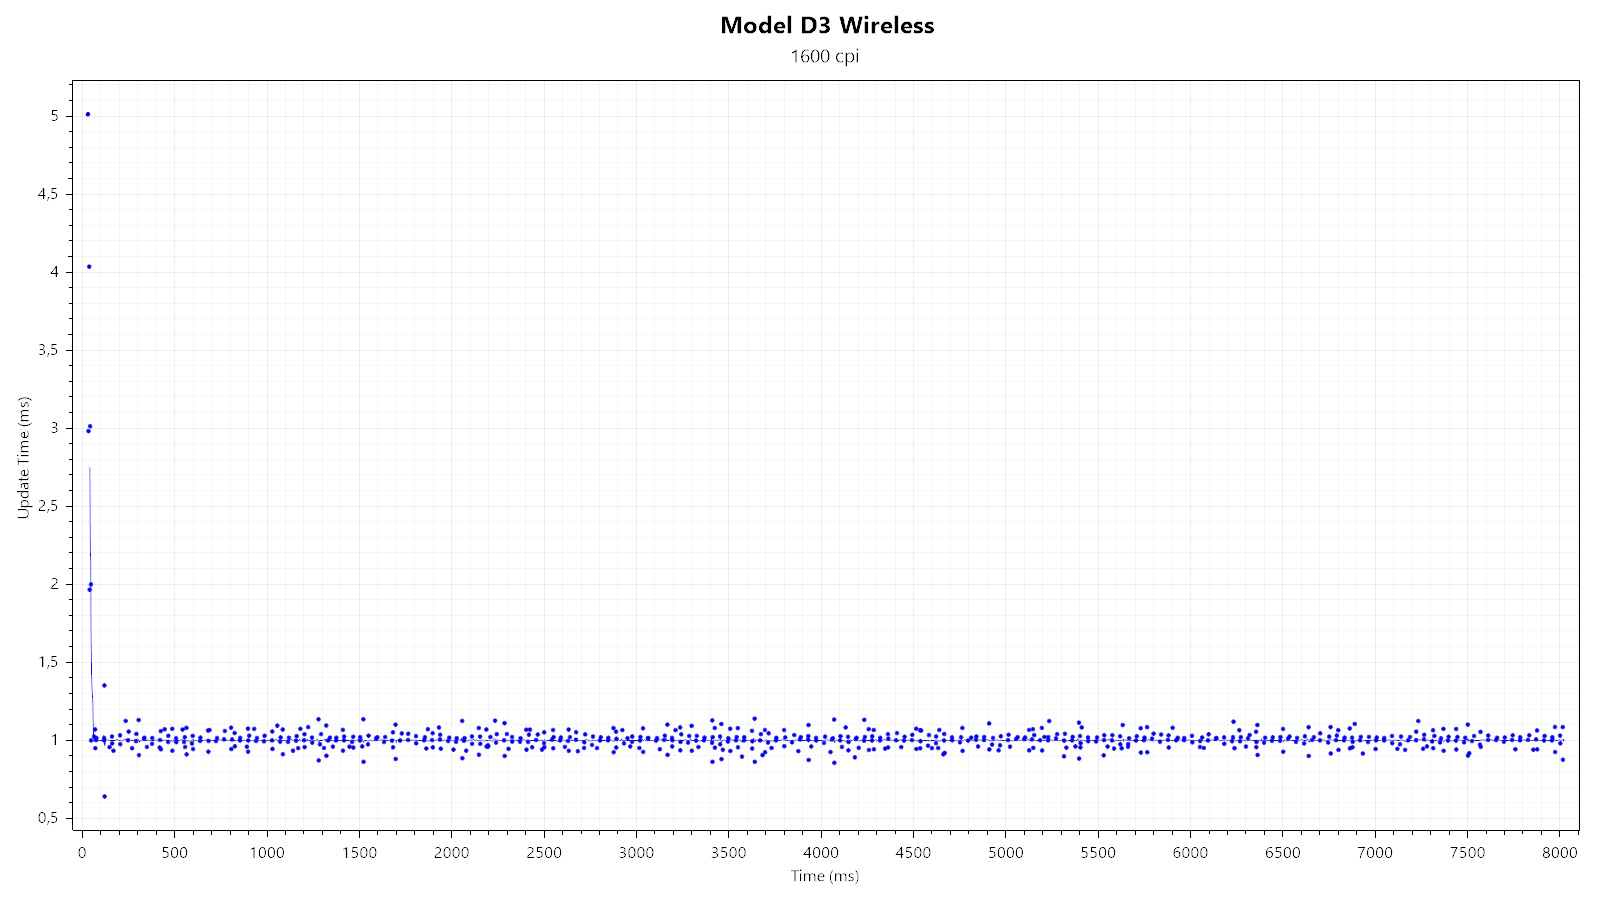
First, I'm testing whether SPI, wireless, and USB communication are synchronized. Any of these being out of sync would be indicated by at least one 2 ms report, which would be the result of any desynchronization drift accumulated over time. I'm unable to detect any periodic off-period polls that would be indicative of a desynchronization drift.
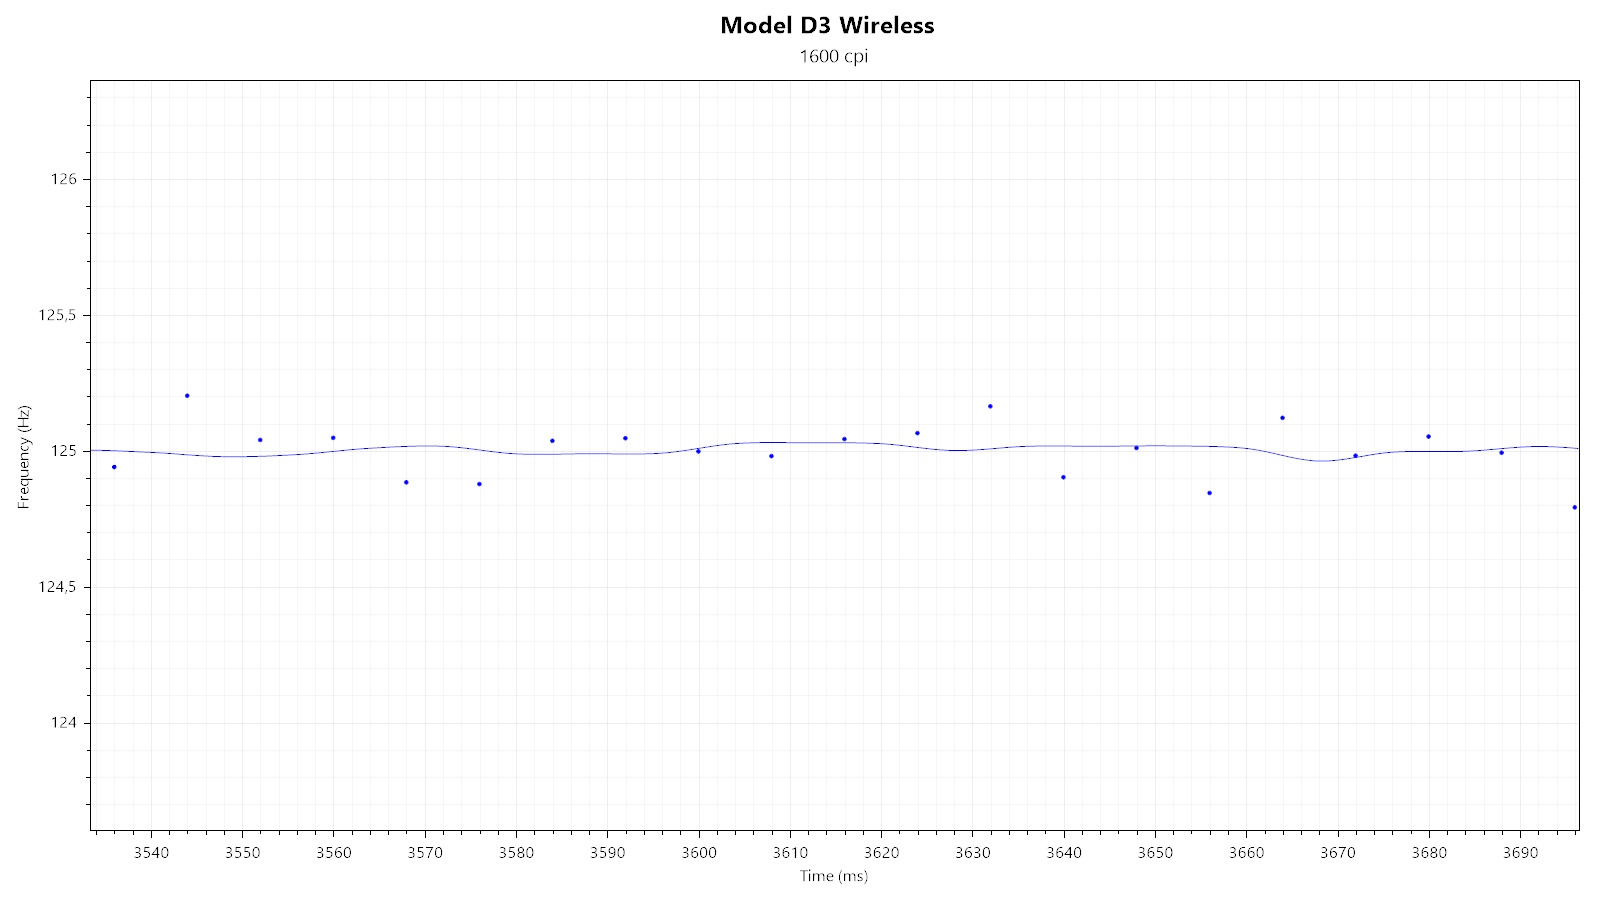
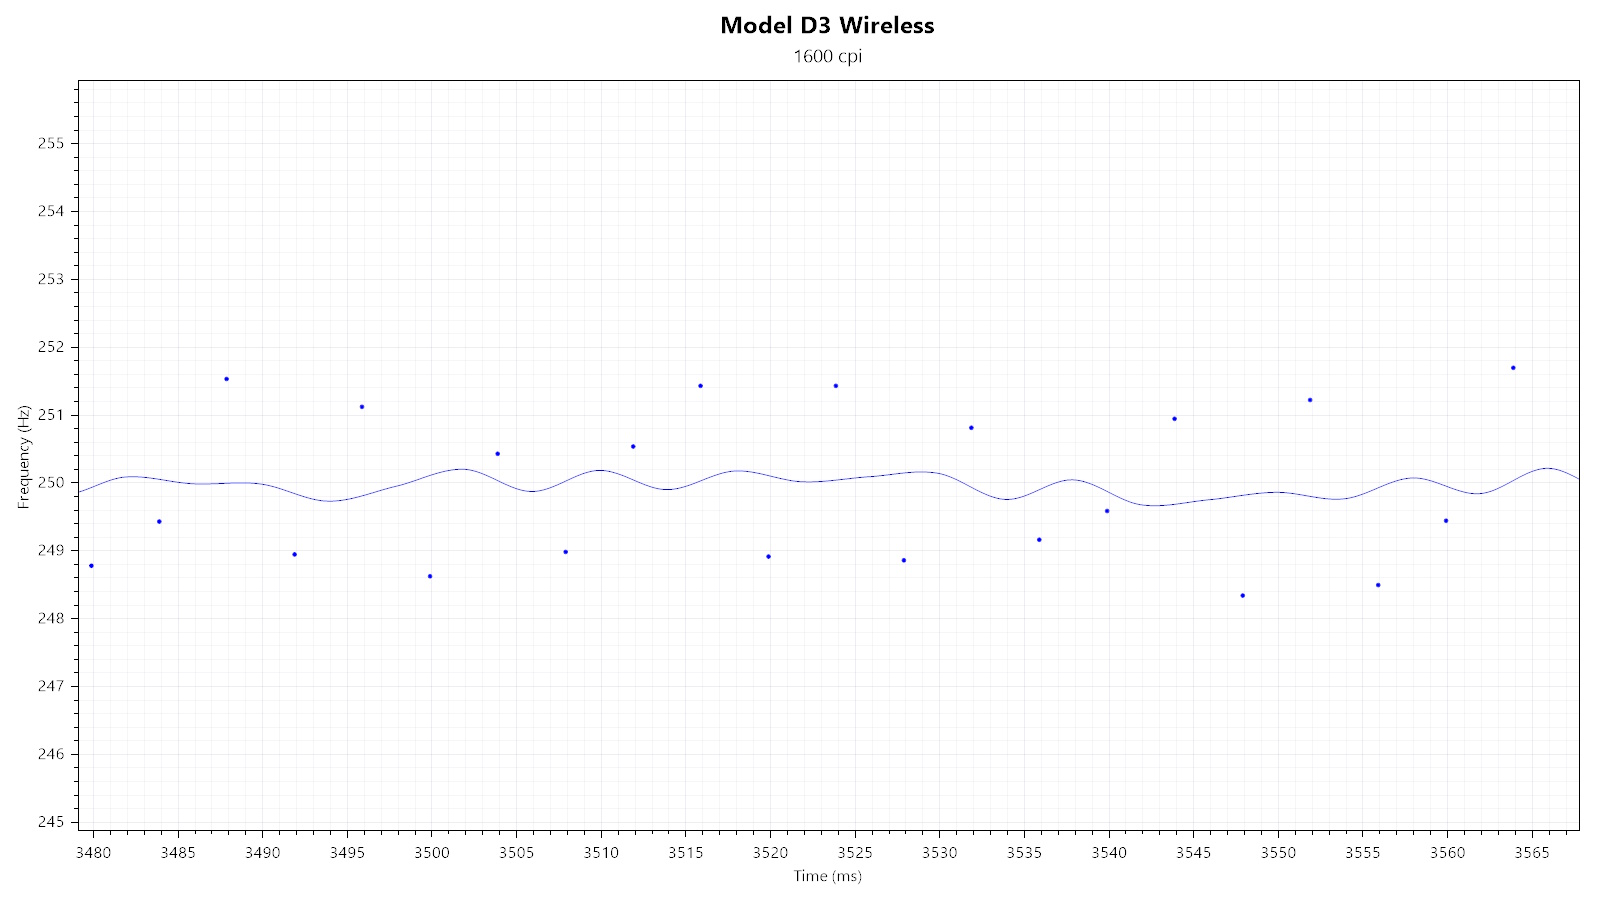
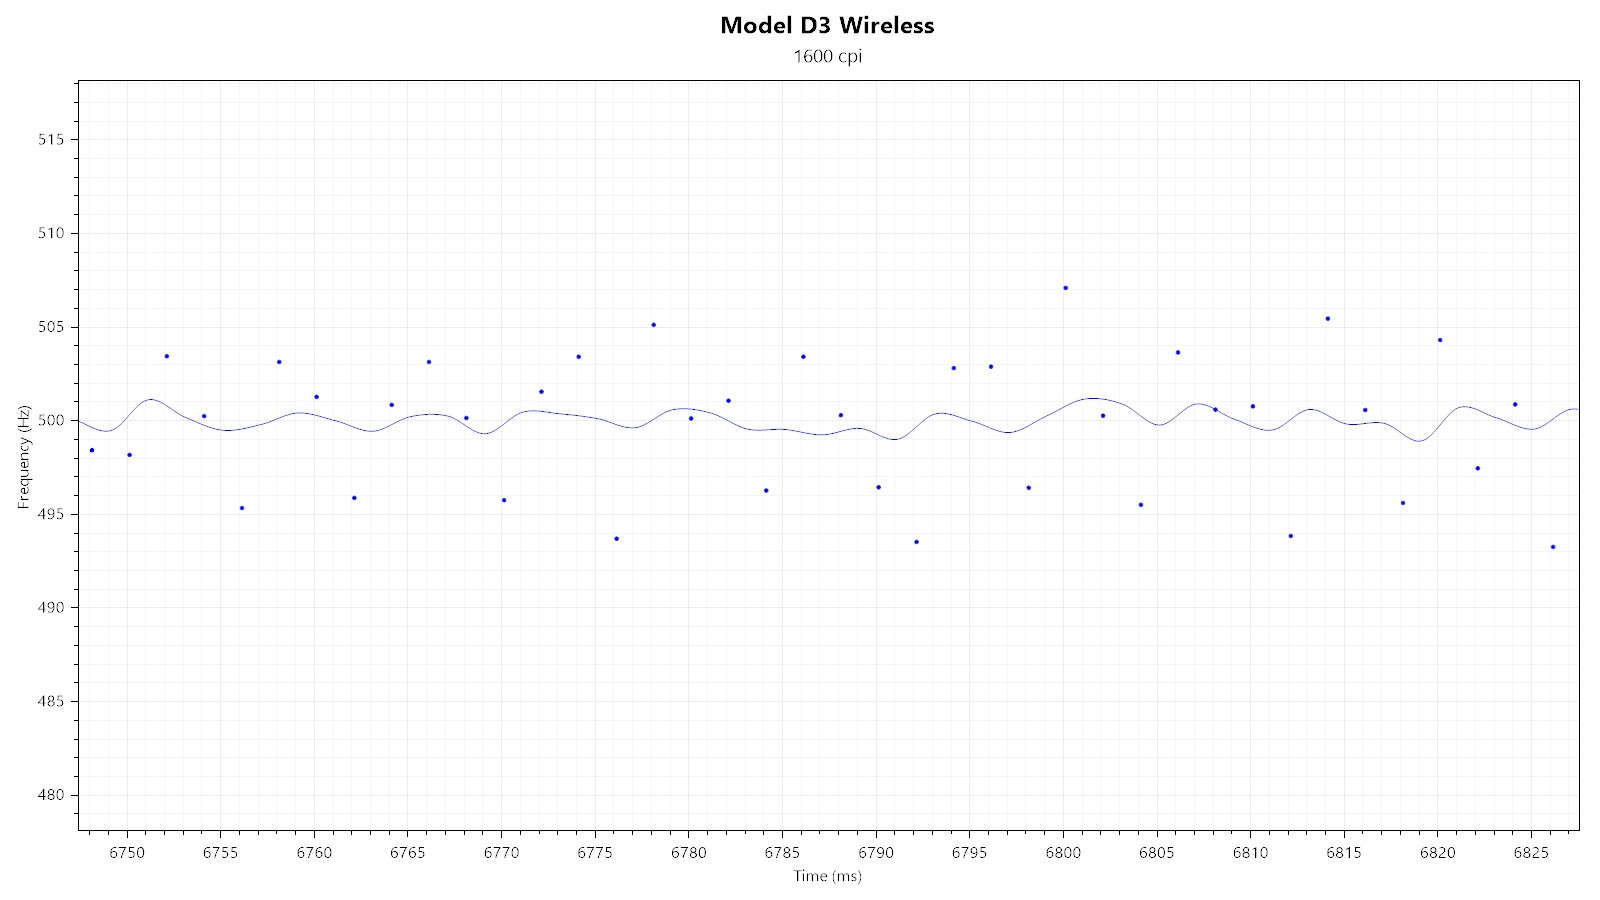
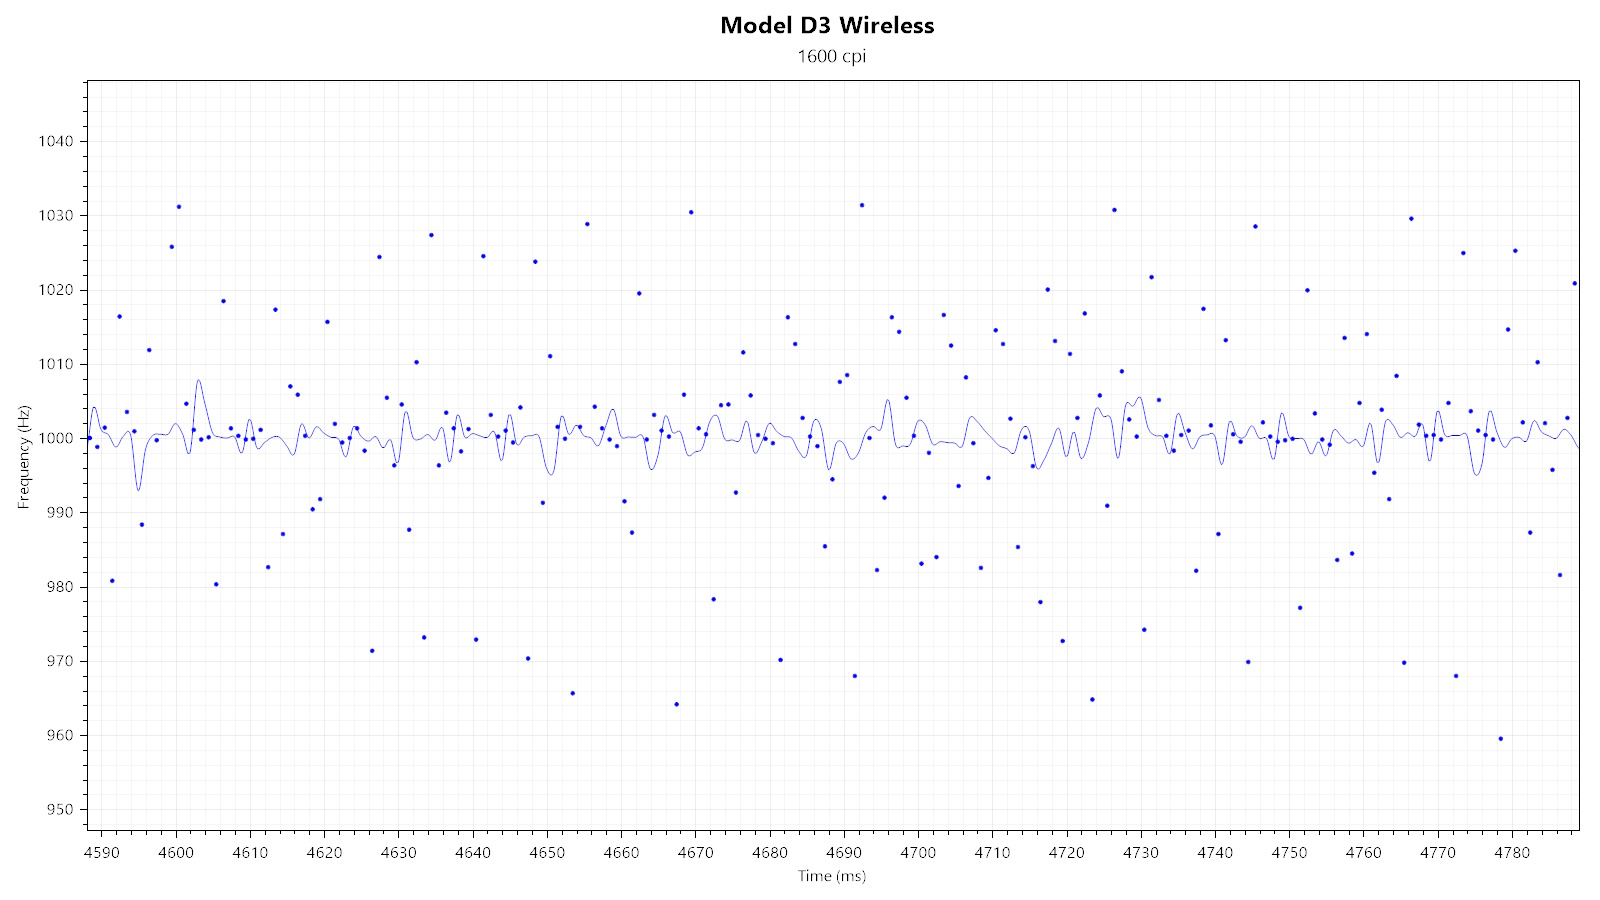
Second, I'm testing the general polling-rate stability of the individual polling rates in wireless mode. Running the Model D3 Wireless at a lower polling rate can have the benefit of extending battery life. All polling rates are fully stable.
Paint Test
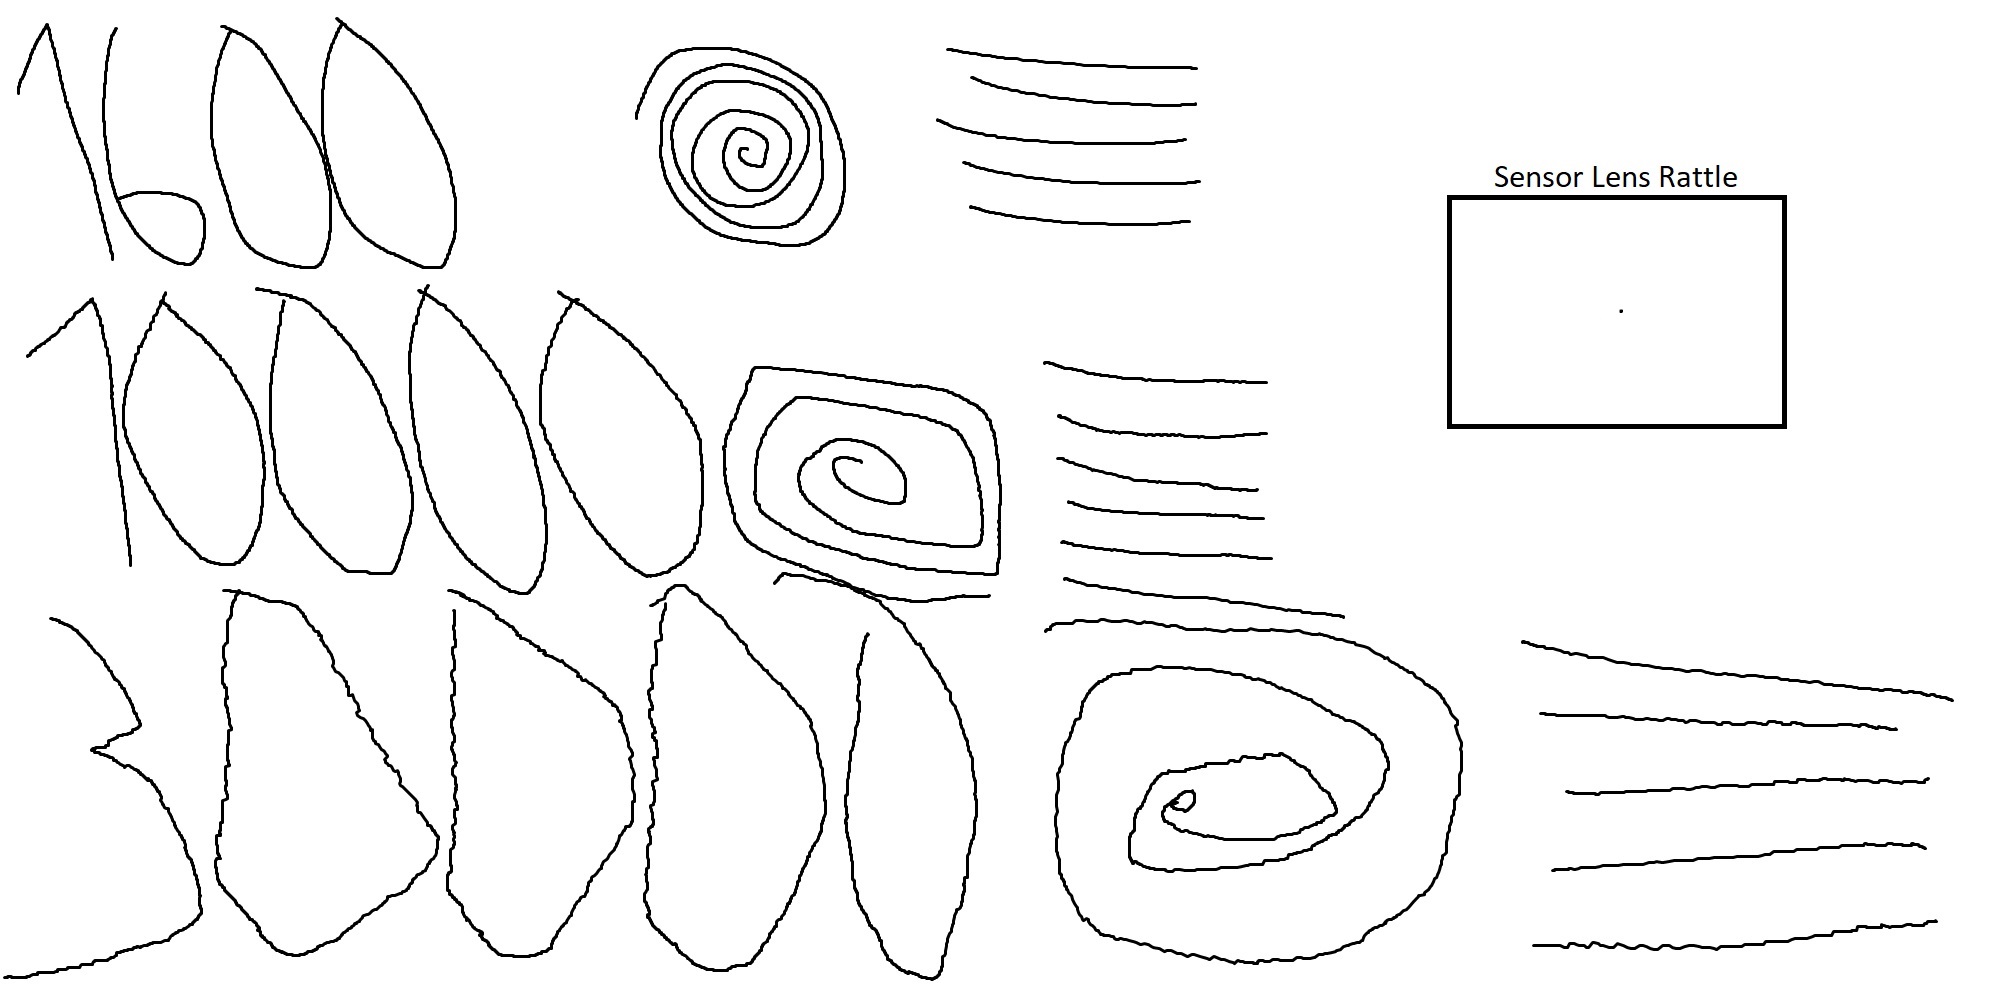
As you can see, no issues with angle snapping can be observed. There is no jitter visible at 1600 CPI. 10,000 CPI shows moderate jitter, which is elevated to major levels at 30,000 CPI. This is in line with what to expect from a sensor lacking any smoothing. Lastly, there is no lens movement.
Lift-off Distance
The Model D3 Wireless offers three pre-defined LOD levels. On the "0.7 mm" and "1 mm" settings, the sensor does not track at a height of one DVD. Using the "2 mm" setting, the sensor does track at a height of one DVD, but not at a height of two DVDs (1.2<x<2.4 mm; x=LOD height). I've been able to confirm through other means that the 0.7 and 1 mm settings do provide different LOD. Keep in mind that LOD may vary slightly depending on the mousing surface (pad) it is being used on.
Click Latency
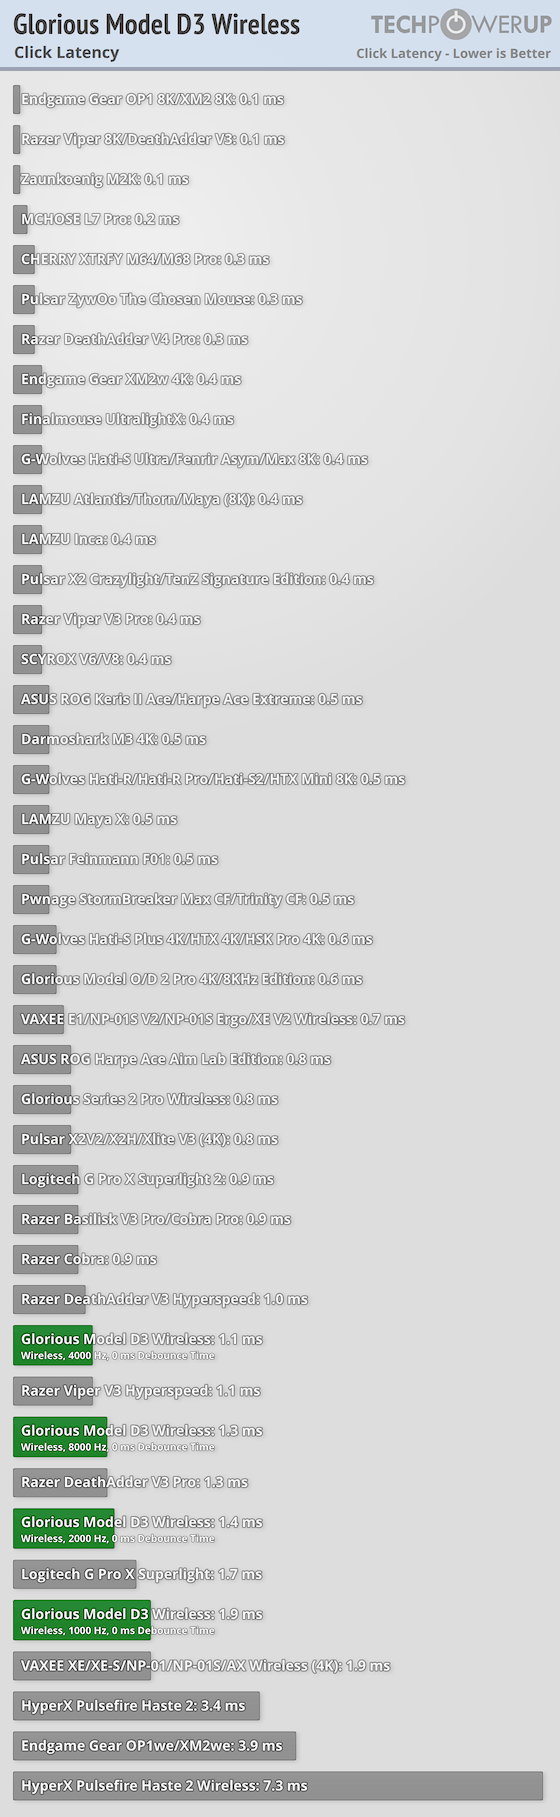
Testing in wired mode proved to be impossible, which is why testing is restricted to wireless mode. At 1000 Hz and a debounce time of 0 ms, click latency has been measured to be 1.9 ms, with standard deviation being 0.47 ms. At 2000 Hz and a debounce time of 0 ms, click latency has been measured to be 1.4 ms, with standard deviation being 0.22 ms. At 4000 Hz and a debounce time of 0 ms, click latency has been measured to be 1.1 ms, with standard deviation being 0.26 ms. At 8000 Hz and a debounce time of 0 ms, click latency has been measured to be 1.3 ms, with standard deviation being 0.24 ms. Debounce time scales largely linearly.
Nov 20th, 2026 14:05 PST
change timezone
Latest GPU Drivers
New Forum Posts
- How to prevent OLED burn damage due to PC freezes or power outtages? (48)
- Honestly, do you care about GTA VI? (208)
- When you could finally run Crysis maxed out? (63)
- WarpCoreBench scores! (80)
- GTA VI (20)
- Anthrophics IPO (25)
- GeekMagic Ultra Smart WiFi Weather Station (8)
- Very unusual two gaming-pc scenarios. (35)
- Can i play GTA 6 now? (Joke) (14)
- Zen 3 IF/IMC degradation (239)
Popular Reviews
- AMD Zen 6 Technical Deep Dive
- Ugreen NASync DXP4800 GT Review
- Microsoft Surface Laptop Ultra Review - The Next-gen Arm Laptop
- Corsair RM1200e (Second Generation) Review
- Acemagic Retro X3 Review
- Upcoming Hardware Launches 2027 (Updated Nov 2026)
- Pulsar Office Tour & First Look at P1 Dual-Sensor Mouse
- Biwin Black Opal NV7400 2 TB Review
- AMD Ryzen 7 9800X3D Memory Performance Scaling
- AMD Ryzen 7 9800X3D Review - The Best Gaming Processor
TPU on YouTube
Controversial News Posts
- NVIDIA Co-Founder and CEO Jensen Huang Officially Resigns (490)
- Report: Jensen Huang Eyes NVIDIA Comeback (255)
- Open Letter Asking NVIDIA to Reinstate Jensen Huang Passes 115,000 Signatures (184)
- OpenAI CEO Argues Home PCs Waste the World's Limited DRAM Supply (152)
- NVIDIA Launches Investigation Into Jensen Huang's Relationship With Suspected Chinese Spy (136)
- Intel "Raptor Lake Next" 16-Core and 20-Core CPUs Surface (130)
- Legendary Game Studio BioWare Shuts Down Following EA Layoffs (104)
- Dell CEO Says the Memory Shortage Will Get Worse in 2027 (95)